Iteration at the Boundary of Newton Maps
Hongming Nie

TL;DR
This paper investigates the boundary behavior of holomorphic families of Newton maps of degree at least 3, analyzing their measure limits and rescaling limits through Berkovich dynamics.
Contribution
It provides new estimates for the weak limits of maximal measures and a comprehensive description of rescaling limits for these families.
Findings
Estimate of weak limits of maximal measures
Complete description of rescaling limits
Application of Berkovich dynamics to Newton maps
Abstract
Let be a holomorphic family of degree Newton maps. By studying the related Berkovich dynamics, we obtain an estimate of the weak limit of the maximal measures of . Moreover, we give a complete description of the rescaling limits for .
Click any figure to enlarge with its caption.
 Figure 1
 Figure 2
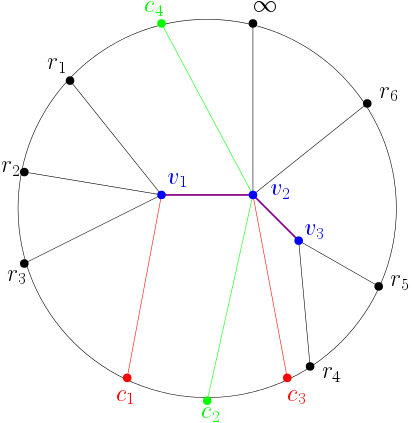 Figure 3
 Figure 4
 Figure 5
 Figure 6
 Figure 7
Peer Reviews
No public reviews on file for this paper yet. If you reviewed it on a platform where reviews are public (OpenReview, ICLR, NeurIPS, ICML), you can paste yours below so the community can read it here.
Videos
No videos yet. Explain this paper in a talk, walkthrough, or lecture? Add one.
Taxonomy
TopicsMathematical Dynamics and Fractals · Advanced Numerical Analysis Techniques · Mathematics and Applications
Iteration at the Boundary of Newton Maps
Hongming Nie
Department of Mathematics, Indiana University
831 East Third Street, Bloomington, Indiana 47405, USA
Abstract.
Let be a holomorphic family of degree Newton maps. By studying the related Berkovich dynamics, we obtain an estimate of the weak limit of the maximal measures of . Moreover, we give a complete description of the rescaling limits for .
1. Introduction
Let be a degree monic polynomial with distinct roots. It can be written as
[TABLE]
where are distinct complex numbers. The Newton map of is defined by
[TABLE]
We also write to indicate the roots of .
As an algorithm for finding the roots of a polynomial, it is also known as Newton’s method, which is a generally convergent for quadratic polynomials. Cayley [8] noticed the difficulties for Newton’s method to find roots of higher degree polynomials. However, there is a finite universal set such that for any root of any suitably normalized polynomial of degree , there is an initial point in the universal set whose orbit converges to this root under iterations of the corresponding Newton’s method [21]. We refer [19, 30, 31, 43, 47] for more details.
As a dynamical system, Newton map exhibits nice properties. The Julia sets of Newton maps are always connected [44]. Moreover, the cubic Newton maps have locally connected Julia sets except in some very specific case [39]. For the combinatorial properties of Newton maps, every postcritically finite cubic Newton map can be constructed by mating two cubic polynomials [48]. For more dynamical properties of Newton maps, we refer [28, 27, 32]. We also refer [49] for an overview of Newton maps. And there also contains detailed background of known results for Newton maps in [40].
The goal of the present article is to investigate the limiting behaviors of a degenerate holomorphic family of Newton maps. We mainly focus on the weak limits of measures of maximal entropy and the rescaling limits. In the subsequent article [35], we will study the compactifications of the related moduli spaces. Now we set up the statement.
For , the space of degree complex rational maps can be naturally identified to a dense open subset of . And in the projective coordinates, for , we can write
[TABLE]
where and are two relatively prime homogeneous polynomials of degree . Generally, for , it determines the coefficients for a pair of homogeneous polynomials of degree . We can write
[TABLE]
where and is a rational map of degree at most . The indeterminacy locus is the collection of , where is a constant in and this constant is a hole of , that is, it is a zero of .
Following DeMarco [9], we can associate each a probability measure . If , the measure is the unique measure such that the measure-theoretic entropy of attains its maximum. If with , the measure is an atomic measure defined on the holes of and all their preimages under . If with , the measure is an atomic measure defined on the holes of . Then the map is continuous if and only if [9, Theorem 0.1].
If we restrict to holomorphic families , then function is better behaved. Let be the Berkovich space over the completion of the field of formal Puiseux series and let be the associated map for . If converges to a point in , by regarding the Berkovich dynamical system as the limit of dynamical systems as , DeMarco and Faber [11, Theorem B] proved the weak limit of measures exists and it is a countable sum of atoms. Later they [12] gave a method to compute the measure by introducing and studying what they call an analytically stable pair , where is a finite set of type II points. Combining with [9, Theorem 0.1], the measure satisfying
[TABLE]
where is the constant value of and is its depth, that is, is the multiplicity of as a zero of .
We now apply this to Newton maps. Suppose is a holomorphic family of degree Newton maps with . If converges to a point , as , then all s converge to , see Lemma 2.15. Thus is the unique hole of and the depth . Let be the weak limit of the maximal measures for . The inequality (1.1) implies
[TABLE]
But the lower bound in inequality (1.2) is not sharp. Our first result is to give a better lower bound for .
Theorem 1.1**.**
Let be a holomorphic family of degree Newton maps. Suppose converges to a point in . Let be the maximal measure for and let be the weak limit of measures . Then
[TABLE]
In particular, if the Gauss point is a periodic point for the associated map for , then .
We point out that in general the lower bound in inequality (1.3) is not sharp either. For example, for quadratic Newton maps, we always have , see Corollary 4.13.
To prove Theorem 1.1, we consider the associated map for . Let be the set of type II repelling fixed points of . Consider the convex hull of and the Gauss point . If the orbit of under the map does not intersects with , we consider the vertices set and study the equilibrium -measures on . Then in this case we can prove . If the orbit intersects with , we construct the vertices sets such that the pairs are analytically stable and then apply [12, Theorem C].
Since the indetermiancy locus is the set of points where the iterate maps are discontinuous [9, Lemma 2.2], it is interesting to explore the limits of holomorphic families converging to points in under iterations. More naturally, we work on the moduli space , modulo the action by conjugation of the group of Möbius transformations.
In quadratic case, the existence of such interesting limits was observed by Stimson [46] in his analysis of the asymptotic behavior of some algebraic curves in . The idea of rescaling limits also appeared in Epstein’s work [14] proving some hyperbolic components are precompact in . Kiwi[25] defined rescaling limits explicitly. For a holomorphic family , the rescaling limits arise as limits of rescaled iterates where the convergence is locally uniform outside some finite subset of . By studying the associated dynamical system and relating the rescalings to the periodic repelling type II points in , Kiwi proved for any given holomorphic one-parameter family of degree rational maps, there are at most dynamically independent rescalings such that the corresponding rescaling limits are not postcritically finite [25, Theorem 1]. Later, applying the trees of spheres, which is based on the Deligne-Mumford compactifications of the moduli spaces of stable curves, and considering the dynamical systems between trees of spheres, Arfeux proved the same results [3, Theorem 1] about the interesting rescaling limits. Moreover, the existence of a periodic sphere for a dynamical cover between trees of spheres corresponds to the existence of a rescaling limit [3, Theorem 2, Theorem 3]. Recently, Arfeux and Cui [2] announced for any arbitrary large integer , there is a holomorphic family in for such that it has dynamically independent rescalings leading to postcritically finite and nonmonomial rescaling limits.
For a holomorphic family of degree Newton maps, we give a complete description for its rescaling limits.
Theorem 1.2**.**
Let be a holomorphic family of degree Newton maps. Then
- (1)
up to equivalence, has at most rescalings of period . Moreover, each such rescaling leads to a rescaling limit that is conjugate to a degenerated Newton map. 2. (2)
* has at most dynamically independent rescalings of periods at least . Moreover, the corresponding rescaling limit for each such rescaling is conjugate to a polynomial of degree at most .*
Let be the associated map for . The period rescalings for correspond to the type II repelling fixed points of . To prove part , we show the type II repelling fixed points are the points that are the branch points in the convex hull whose endpoints are the type I fixed points of . To prove , we first consider the ramification locus and give sufficient and necessary conditions for the existence of generalized rescalings of period at least . Then we count the available critical points of . It will give us the upper bound of the rescalings of higher periods. The main ingredient we use to show the corresponding rescaling limits are conjugate to polynomials is Theorem 1.1. If there exists a rescaling of period , then up to dynamical dependence, we can assume is affine. By the continuity of the composition maps, converges to a point in . We consider the associated map of the holomorphic family . Then the Gauss point is a periodic point of . Thus, by Theorem 1.1, the weak limit of the maximal measures of is the measure . By the invariance of the maximal measures and the continuity of the map if , we know the measure associated to the subalgebraic limit for is . Hence, we can show the rescaling limit is a polynomial. We mention here that can also be obtained from the Berkovich dynamics of the map , see Remark 5.26. Moreover, the subalgrbraic limit of has a unique hole at . Therefore, the upper bound of the degree of the rescaling limits implies this subalgrbraic limit is not semistable, see Proposition 5.30.
Outline
In section 2, we recall the relevant backgrounds of Newton maps and prove there is a unique indeterminacy point in boundary of the space of Newton maps, see Proposition 2.18. Section 3 is devoted to describe the basic Berkovich dynamics of Newton maps. It also contains a backgrounds of Berkovich spaces and related dynamics of rational maps. The goal of section 4 is to study the degenerate holomorphic families of Newton maps in measure-theoretic view. We first state DeMarco and Faber’s results about limiting measures, and then prove Theorem 1.1. Finally we prove Theorem 1.2 and related results in section 5. Kiwi’s results are included in this section.
2. Preliminaries
2.1. Iterate Maps on
For , consider the map
[TABLE]
sending to its -th iterate . Then is proper for all and all [9, Corollary 0.3]. The iterate map extends to a rational map
[TABLE]
Define is the collection of with and the constant value of is a hole of , that is
[TABLE]
The following result, due to DeMarco, claims the indeterminacy loci of the maps are and gives the formula for iteration.
Lemma 2.1**.**
[9, Lemma 2.2]** For and , the indeterminacy locus of the iterate map is . Moreover, for ,
[TABLE]
More general, for the composition maps, we have
Lemma 2.2**.**
[10, Lemma 2.6]** The composition map
[TABLE]
which sends a pair to the composition is continuous away from
[TABLE]
Moreover, for ,
[TABLE]
where .
2.2. Convergence
In this subsection, we consider various notations of convergence of maps in the space of (degenerate) rational maps. Mainly, we define the subalgebraic convergence and show the relations between subalgebraic convergence and locally uniform convergence on the complement of a finite set in .
First recall that for , a collection is a 1-dimensional holomorphic family of degree rational maps if the map , sending to , is a holomorphic map such that if . We say is degenerate if . A holomorphic family of degree rational maps is called a moving frame.
Definition 2.3**.**
For a holomorphic family , we say converges to subalgebraically if converges to in as . If, in addition, , we say converges to algebraically.
Let’s use the notations and for subalgebraic convergence and algebraic convergence, respectively. Moreover, for a finite subset , denote on if converges to locally uniformly on , and denote if converges to uniformly on .
Lemma 2.4**.**
[25, Lemma 3.2 ]** For a holomorphic , suppose that . Then on .
Conversely, we have
Lemma 2.5**.**
Let be a holomorphic family. Suppose that on , where is finite. Then there exists a degree homogeneous polynomial such that with .
Proof.
Suppose that , as . Then by Lemma 2.4, we have on . Thus on . So on . We get . Thus, . ∎
Corollary 2.6**.**
Let be a holomorphic family. Then if and only if .
We use the following example to illustrate the subalgebraical convergence.
Example 2.7**.**
Quadratic rational maps.
Here we consider the fixed-point normal form for quadratic rational maps [33, Appendix C].
[TABLE]
with . Then and are fixed points of with multipliers and , respectively. And the third fixed point is with multiplier .
In projective coordinates, we can write
[TABLE]
Then . Consider the holomorphic family given by
[TABLE]
with . Then is degenerate. Suppose as . We have
[TABLE]
and
[TABLE]
2.3. (Degenerate) Newton Maps
In this subsection, we state some basic background of the (degenerate) Newton maps. For , let be a degree monic polynomial. Let be the roots of counted with multiplicity. Then is uniquely determined by . We may write instead of to emphasis its roots. In projective coordinates, we can write
[TABLE]
Then the derivative of can be written as
[TABLE]
Define
[TABLE]
We say is a Newton map of degree if . In other word, is a Newton map of degree if and only if are distinct points in . In this case, in affine coordinates, we can write by
[TABLE]
and say is the Newton map of the polynomial .
For a point , we say is a degenerate Newton map of degree if there exists a sequence of Newton maps of degree such that converges to in , as . Let be a degenerate Newton map of degree . Then there exist an integer and a degree polynomial such that
[TABLE]
If , then is a hole of with depth . All other holes of are the multiple roots of and the corresponding depths are , where is the multiplicity of as a zero of . Note if , then is a degree polynomial with multiple roots, and the formula (2.3) coincides to formula (2.1).
In general, let be a set of points (not necessary distinct) in . Suppose there are many s in . Let be the polynomial of degree whose roots coincide to the points in that are not . Then we define to be the (degenerate) Newton map by formula (2.3).
Example 2.8**.**
Let . Then has holes at [math] and , and each hole has depth . More precisely,
[TABLE]
Note here we have .
For , denote by , and for the set of fixed points, the set of zeros and the set of critical points of , respectively. Now we state some basic facts about the Newton map .
Proposition 2.9**.**
For , let be a set of distinct points in , and let be the Newton map of the polynomial . Then
- (1)
The set of fixed points of is
[TABLE]
All ’s are superattracting fixed points and is the unique repelling fixed point. Moreover, the multiplier of at is . 2. (2)
The derivative of is
[TABLE]
In particular,
Remark 2.10**.**
If is a degenerate Newton map, then we still have
[TABLE]
But may not be a superattracting fixed point. In fact, it is an attracting fixed point with multiplier , where is the multiplicity of as a zero of . Moreover, the depth .
For a Newton map of degree with , at each , there is a neighborhood such that for each , as . The Bttcher’s theorem [34, Theorem 9.1] implies that this convergence is at least quadratic. We say a critical point is free if . If has an attracting cycle of period at least , then at least one free critical point is attracted to this cycle.
In the case , we can conjugate by some such that the two superattracting fixed points of are [math] and . This fact is known by Cayley, see [1] for more history. Thus, we have
Proposition 2.11**.**
Any quadratic Newton map is conjugate to .
2.4. The Space
For , denote by the set of degree Newton maps. Then
[TABLE]
Let be the closure of in .
Let be a set of distinct points. Then
[TABLE]
and
[TABLE]
where the ’s are the elementary symmetric functions of ’s. In projective coordinates, we can express the Newton map as following
[TABLE]
Remark 2.12**.**
- (1)
The formula (2.4) of also works for the degenerate Newton map of degree for which is not a hole. 2. (2)
In general, let be the set of points (not necessary distinct) in . Suppose there are many s that are . Then we can write , where is the subset consisting of . The formula 2.4 gives the projective coordinate of . Hence, we can get the projective coordinates of .
Since a holomorphic family of rational maps is a family in which the coefficients may be expressed as holomorphic functions of the parameter , the locations of the fixed points are thus algebraic functions of this parameter. It is well-known that algebraic functions of one complex variable t are given by Puiseux series in , see [41]. Thus by a change in the parameterization of the form we may assume that the fixed points themselves are holomorphic functions of one parameter. In summary, when considering holomorphic families of Newton maps, it suffices for our purposes to consider holomorphic families where the roots are holomorphic functions of .
Now we state an easy lemma to show the subalgebraic limit of a holomorphic family of Newton maps.
Lemma 2.13**.**
Let be a holomorphic family of degree Newton maps with . Suppose as , then in projective coordinates,
[TABLE]
where .
We use the following example to illustrate Lemma 2.13. And we draw the corresponding dynamics plane by the software “fractalstream”.
Example 2.14**.**
- (1)
Let . Consider the Newton map . As , we have
[TABLE] 2. (2)
Let . Consider the Newton map . As , we have
[TABLE]
Recall is the indeterminacy locus. Then
Lemma 2.15**.**
Let be a holomorphic family of degree Newton maps. Suppose as . Then if and only if for all .
Proof.
If for , then as , we have and for ,
[TABLE]
Hence, by formula (2.4), as ,
[TABLE]
Thus, .
Conversely, let . By Lemma 2.13, since . If , suppose and , as . Then . Thus, in this case . So , that is, all , as . ∎
Corollary 2.16**.**
If with , then .
Corollary 2.17**.**
Let be a holomorphic family of degree Newton maps with . Suppose for some as , and suppose . Then for any , and hence outside a finite set.
Proof.
From Lemma 2.15, we have . It follows the Lemmas 2.1 and 2.4. ∎
Lemma 2.15 implies immediately the following fundamental result.
Proposition 2.18**.**
For ,
[TABLE]
3. Berkovich Dynamics
3.1. Berkovich Space and Related Dynamics
In this subsection, we summarize the definitions and main properties of Berkovich spaces and rational maps on Berkovich spaces used in this work. For more details, we refer [4, 6, 5, 22, 37, 38].
Let be the field of formal Puiseux series over . Then can be equipped with a non-Archimedean absolute value by defining
[TABLE]
where is the smallest integer such that . For more details of non-Archimedean fields, we refer [13]. Then the field is algebraically closed but not complete. Let be the completion of the field , see [23, 24, 25]. It consists of all formal sums of the form , where is a sequence of rational numbers increasing to and . Let be the extension of the non-Archimedean absolute value so that . To abuse of notations, we may write for . Then the ring of integers of the field is
[TABLE]
and the unique maximal ideal of consists of series with zero constant term, i.e.
[TABLE]
The residue field is canonically isomorphic to .
Let be the value group of . Given and , define
[TABLE]
If , we say that is an open rational disk in and is a closed rational disk in . If , then . And we call it an irrational disk. Let be a disk centered at with radius , that is, has the form or . Then if , we have . Moreover, the radius is the same as the diameter of , that is . Furthermore, if two disks have a nonempty intersection, then one must contain the other. Finally, we should mention here every disk in is both open and closed under the topology of .
The Berkovich affine line is the set of all multiplicative seminorms on the ring of polynomials over , whose restriction to the field is equal to the given absolute value . To ease notation, we may write for . For and , let be the seminorm defined by
[TABLE]
for . Then there are types of points in :
-
Type I. for some .
-
Type II. for some and .
-
Type III. for some and .
-
Type IV. A limit of seminorms , where the corresponding sequence of closed disks satisfies and .
We can identify with the type I points in via . The point is called the Gauss point and denoted by . We put the Gelfand topology (weak topology) on , which makes the map , sending to , continuous for each . Then is locally compact, Hausdorff and uniquely path-connected.
For , we say if for all polynomials . For types I, II and III points, if and only if . Then is a partial order on . Denote by the least upper bound with respect to the partial order . Then always exists and is unique. The small metric on is defined by
[TABLE]
where is the affine diameter of the point , that is, if is a sequence of seminorms converging to , then . The topology on induced by the metric is called the strong topology. It is strictly finer than the weak topology. The Berkovich hyperbolic space is defined by
[TABLE]
Then we define the path distance metric on by
[TABLE]
The restriction of the strong topology to coincides with the metric topology induced by . The space is complete for this metric, but not locally compact.
The Berkovich projective line is obtained by gluing two copies of along via the map . Then we can associate the Gelfand topology and strong topology on . Under the Gelfand topology, The Berkovich projective line is a compact, Hausdorff, uniquely path-connected topological space and contains the projective line as a dense subset.
The space has tree structure. For a point , we can define an equivalence relation on , that is, is equivalent to if and are in the same connected component of . Such an equivalence class is called a direction at . We say that the set formed by all directions at is the tangent space at . For , denote by the component of corresponding to the direction . If is a type I or IV point, consists of a single direction. If is a type III point, consists of two directions. If is a type II point, the directions in are in one-to-one correspondence with the elements in . Since the Gauss point is a type II point, we can identify to by the correspondence sending to , where is the direction at such that contains all the type I points whose images are under the canonical reduction map .
The spherical metric on the projective is defined as follows: for points and in ,
[TABLE]
Equivalently,
[TABLE]
Recall a degree rational map is represented by a pair of degree homogeneous polynomials with no common factors, that is, for all . Equivalently, the map can be considered as the quotient of two relatively prime polynomials, of which the greatest degree is . Then induces a map from to itself. We use the same notation for the induced map. For the Gauss point , the corresponding closed disk is a disjoint union of open disks for . Note for all but finitely many such , we have is an open disk for some . Then is the point for any such choice of . For an arbitrary type II point , pick such that . Then apply the previous discussion to and . Since type II points are dense in , we can get the image for any .
For a holomorphic family
[TABLE]
of degree rational maps, let be the power series expressions of the coefficients , respectively. Then the degree rational map given by
[TABLE]
is called, following Kiwi [25], the rational map associated to . Hence induces a map .
Let be a polynomial and let be the image of in . We say is the reduction of . For a rational map , where with no common zeros. We can normalize such that and the maximal absolute value of coefficients of and is . For a normalized rational map , the reduction is defined by
[TABLE]
In fact, if is induced from a holomorphic family, the reduction coincides with the limit of as . For convenience, for an arbitrary rational map , we write for the reduction of the normalization of .
Lemma 3.1**.**
Let be two rational maps. Then
- (1)
, 2. (2)
, 3. (3)
If , then .
The following result, originally proved by Rivera-Letelier, gives a characteristic of rational maps with nonconstant reductions.
Proposition 3.2**.**
[4, Corollary 9.27]** Let be a normalized rational map. Then if and only if .
At each point , denote by the local degree of at . Then
Lemma 3.3**.**
[4, Section 9.1]** Let be a nonconstant rational map. Let and . Then there is a positive integer and a point such that
- (1)
* for all , and* 2. (2)
* for all .*
The integer is called the directional multiplicity and denoted by .
Let . For any , there is a unique such that for any sufficiently near , . Thus the rational map induces a map
[TABLE]
sending the direction to the corresponding direction .
The following lemma gives the relations between local degrees and directional multiplicities.
Lemma 3.4**.**
[4, Theorem 9.22]** Let be a nonconstant rational map. Let . Then
- (1)
for each tangent , we have
[TABLE] 2. (2)
the induced map is surjective. If is of type I, III, or IV, then for each .
The following result allows us to compute the local degree of at a type II point.
Proposition 3.5**.**
[36, Proposition 3.3]** Let be a nonconstant rational function, and let be a type II point. Set and choose such that and . Let . Then and
[TABLE]
For each , if is the associated tangent direction under the bijection between and afforded by , we have
[TABLE]
Now let’s state a fundamental fact in Berkovich dynamics.
Proposition 3.6**.**
[36, Lemma 2.1]** Let be a rational map of degree at least . For and , the image always contains , and either or . Moreover
- (1)
if , then each has preimages in , counting multiplicities; 2. (2)
if , there is an integer such that each has preimages in and each has preimages in , counting multiplicities.
Following Faber [15], the integer is called the surplus multiplicity.
The following lemma gives us a criterion for which Berkovich disk is mapped to another Berkovich disk.
Lemma 3.7**.**
[4, Theorem 9.42]** Let be a nonconstant rational map. Then is a Berkovich disk if and only if for each , the local degree of is nonincreasing on the directed segment .
3.2. Berkovich Dynamics of Newton maps
Fix . Let
[TABLE]
be a set of distinct points. Set . Same as complex case, the Newton map of the polynomial is defined by
[TABLE]
The map extends to a map . To ease notation, we write for . In this subsection, we state some fundamental properties of in the Berkovich space . These properties shed light on the case when we consider holomorphic families of Newton maps. Indeed, if is a holomorphic family of degree Newton maps with , by regarding each as an element in , the associated map for is a Newton map in .
Since is a complete and algebraically closed field of characteristic zero, the map has critical points, counted with multiplicity, in . Thus the collections is a finite collection of elements in , which sits in the Berkovich space . Let be convex hull of . As a topological space, is homeomorphic to the underlying space of a finite tree. We may equip this undelying space with a natural graph-theoretic combinatorial structure so that we may speak of vertices and edges. Consider the branch points as the vertices of . Then is a finite tree and it plays a central role in our study. Since it is the biggest of several trees we will consider, we indicate this by the subscript.
In general, the vertices of come in two flavors: (1) those in the hyperbolic space , which are called the internal vertices of the tree, and (2) those in , i.e. the critical points and the point , which are called the leaves of the tree. Note the fixed points of in are s and . Then the convex hull of sits in . As for , we can consider vertices, internal vertices and leaves for . Then a vertex of is a vertex of . Hence is a subtree of . Let be the set of internal vertices of . We have
[TABLE]
where is the valance of in a connected subset , that is, the number of components of . Thus each element in is an internal vertex of . The convex hull spanned by is a subset of . It also play a key role. The path distance metric on gives a natural metric structure that we study in section 5. Moreover, as we will discuss in [35], the combinatorial tree encodes the stratum in the Deligne-Mumford compactification of the moduli space of Riemann surfaces of genus [math] with marked points to which the configuration converges.
To make it clear, we list the subtrees we will study.
[TABLE]
where .
To illustrate the these subtrees, we first define visible point, which was introduced by Faber [16]
Definition 3.8**.**
For a connected subset and a point , we say a point is the visible point from to if is the unique point of closure of (in strong topology) minimize the small metric from to . Denote by the visible point from to .
Note if , we have . If , then is the unique point on disconnecting from .
Now we illustrate the several subtrees in . As an motivating example, we consider
Example 3.9**.**
Let and be six points in . Set and consider the map . Then has four free critical points and . Figure 3 shows the convex hull for . The hull has internal vertices and leaves . Let and . At , the reduction of has degree . Hence there are critical points of whose visible points to are . At , the map has superattracting fixed point and attracting fixed points. Thus there are at least two directions whose corresponding Berkovich disks containing free critical points, say , attracted to these two attracting fixed points. At , the reduction of has degree .
For now, we focus on combinatorial aspects. The following theorem summarizes the properties of these subtrees. The proof depends on a sequence of lemmas established later in this subsection.
Theorem 3.10**.**
For a Netwon map of degree , consider the subtrees defined as above. Then we have
- (1)
The set is a singleton if and only if the map has a potentially good reduction. 2. (2)
Let be the set of fixed points of in . Then
[TABLE] 3. (3)
The visible points from elements in to lie in . Moreover, for each , there are points, counted with multiplicity, in whose visible points to are . 4. (4)
For each , the visible points from the preimages to lie in . 5. (5)
The set is forward invariant and contains . Moreover, edges of maps to themselves. In particular, each point in is attracted to some . 6. (6)
*The Berkovich ramification locus of consists of the union of closed segments *s, where and is the visible point from to .
Remark 3.11**.**
In Theorem 3.10, the assumption is necessary. Indeed, if , then and is always a singleton. Hence is a segment and the ramification locus is connected which is . But Theorem 3.10 are still true for .
If is a singleton, then . Hence . Let such that . Then . By Proposition 3.5, we have . Hence has a potentially good reduction. Conversely, if has a potentially good reduction, then there exits such that . So . Letting , we have . Hence is a singleton. This gives the proof of Theorem 3.10 .
Lemma 3.12**.**
.
Proof.
Note
[TABLE]
Then . Thus . Hence . Since , we have
[TABLE]
The conclusion follows from the uniqueness of the visible point. ∎
For a rational map and a type II point , Proposition 3.2 claims that if and only if the reduction is nonconstant, where and such that . A fixed point is repelling if . For the map , the points and are the only fixed points of type I. Now we show
Lemma 3.13**.**
For the map ,
[TABLE]
In particular, the set of repelling fixed points of in is .
Proof.
If is a type II point, let such that . Then the reduction of is nonconstant. Indeed, is a Newton map for a polynomial in with multiple roots. If is not a type II point, there exists a sequence of type II points such that as . Note is continuous. Then
[TABLE]
Thus .
If is a type II point, let such that . Then there exist at least many ’s such that . Thus, the reduction of is constant. So . For any type III or IV point , the visible point is a type II point. Let be such that . By Lemma 3.7, we know is a Berkovich disk. Since is not a fixed point of the map ,
[TABLE]
So . Therefore, .
Now we show that the set consisting of repelling fixed points in . Let be a type II point. Let such that . If , then is either or some constant . Thus, the reduction has degree . Then by Proposition 3.5, . So is not a repelling fixed point. If , then there exist two distinct constants and in , and exist and with such that and . Thus, the reduction has degree at least . Again, by Proposition 3.5, we have . Thus is a repelling fixed point. ∎
Corollary 3.14**.**
.
Proof.
First note at , the local degree . By the definition of and Lemma 3.13, we know
[TABLE]
For the other direction, let . By Lemma 3.13, we have . Suppose is of type II. Let be such that . Then has reduction of degree at most . By Proposition 3.5, we have . By the density of type II points and Lemma 3.3, we know . ∎
Recall that a point is a free critical point of if . The following lemma gives the visible points of critical points to the tree and hence implies Theorem 3.10 .
Lemma 3.15**.**
If is a free critical point, then . Moreover, for ,
[TABLE]
counted with multiplicity.
Proof.
To ease the notations, let . Then is a type II point. Let be the tangent vector such that . Then the directional multiplicity since is a critical point of . Thus by Lemma 3.4, we have
[TABLE]
By Corollary 3.14, we have .
For , by the definition of and Lemma 3.13, we know is a type II fixed point of . Let such that . Then the reduction has critical points. Note
[TABLE]
and
[TABLE]
Thus we obtain the conclusion. ∎
Now we prove a weak version of Theorem 3.10 which allows us to characteristic the fixed Berkovich Fatou components of and hence prove Theorem 3.10. After that, we prove Theorem 3.10.
Lemma 3.16**.**
For , let . Then
[TABLE]
Moreover, for ,
[TABLE]
Proof.
Suppose . By Lemma 3.13 and Corollary 3.14, we have and . Let