Deformation and singularities of maximal surfaces with planar curvature lines
Joseph Cho, Yuta Ogata

TL;DR
This paper refines the classification of maximal surfaces with planar curvature lines in Lorentz-Minkowski space, introduces a deformation connecting all such surfaces, and studies their singularities and conjugates.
Contribution
It provides an alternative classification method, demonstrates a continuous deformation among these surfaces, and explores their singularities and conjugate counterparts.
Findings
Existence of a deformation connecting all maximal surfaces with planar curvature lines.
Characterization of singularities on these maximal surfaces.
Results on conjugate surfaces that are affine minimal.
Abstract
Minimal surfaces with planar curvature lines in the Euclidean space have been studied since the late 19th century. On the other hand, the classification of maximal surfaces with planar curvature lines in the Lorentz-Minkowski space has only recently been given. In this paper, we use an alternative method not only to refine the classification of maximal surfaces with planar curvature lines, but also to show that there exists a deformation consisting exactly of all such surfaces. Furthermore, we investigate the types of singularities that occur on maximal surfaces with planar curvature lines. Finally, by considering the conjugate of maximal surfaces with planar curvature lines, we obtain analogous results for maximal surfaces that are also affine minimal surfaces.
Click any figure to enlarge with its caption.
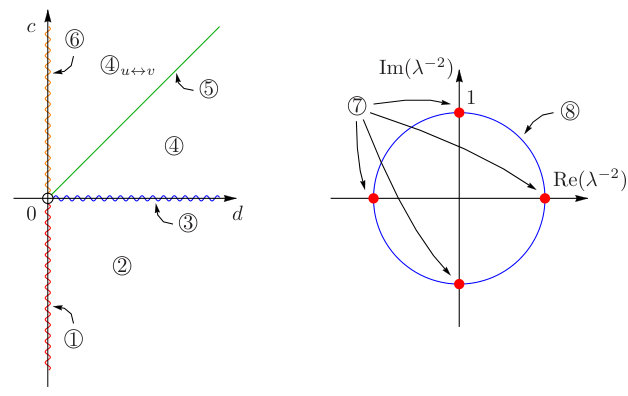 Figure 1
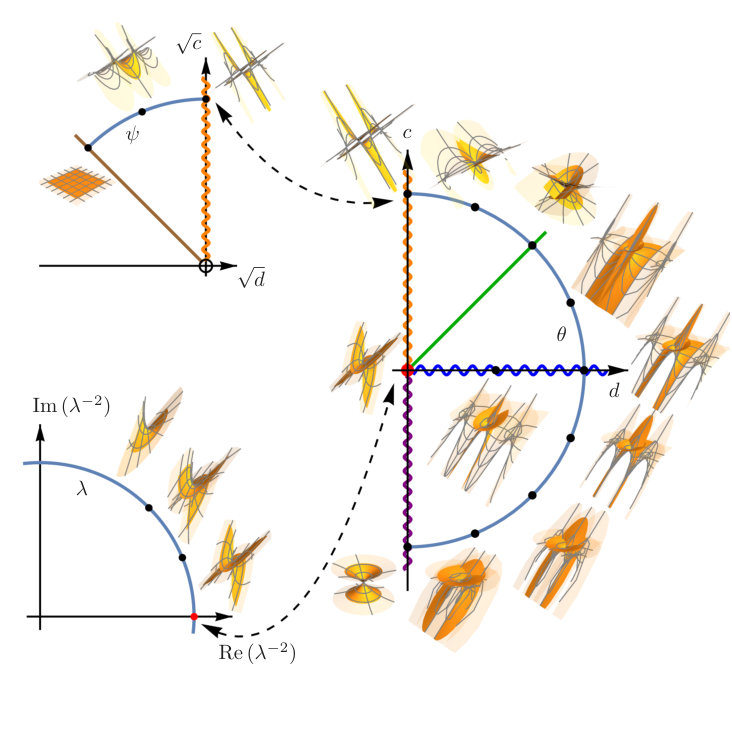 Figure 2
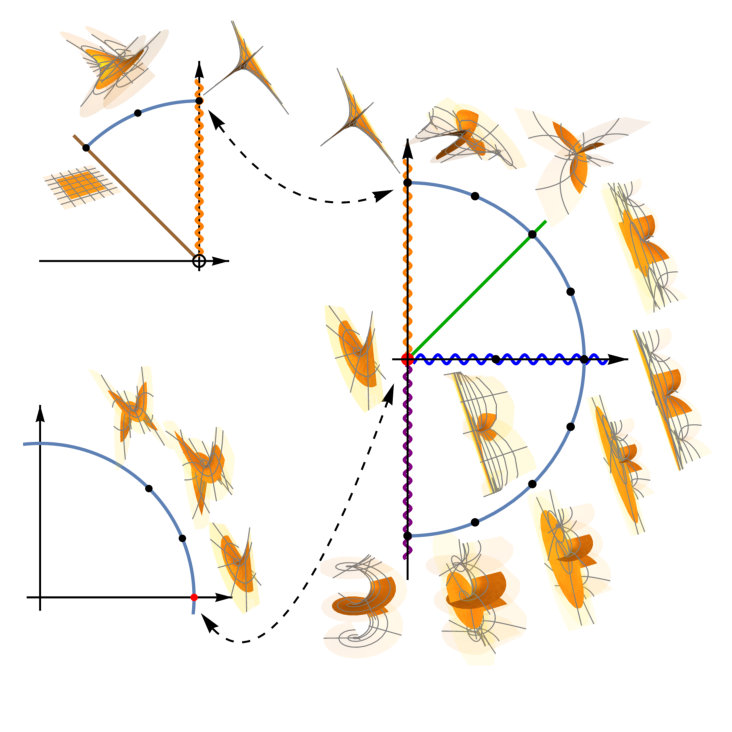 Figure 3
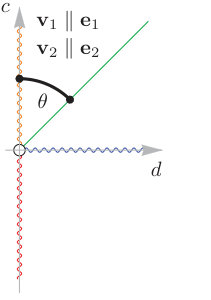 Figure 4
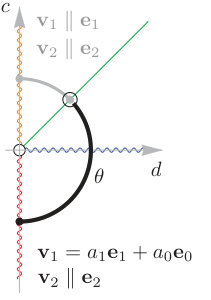 Figure 5
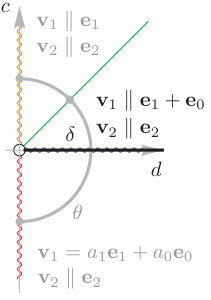 Figure 6
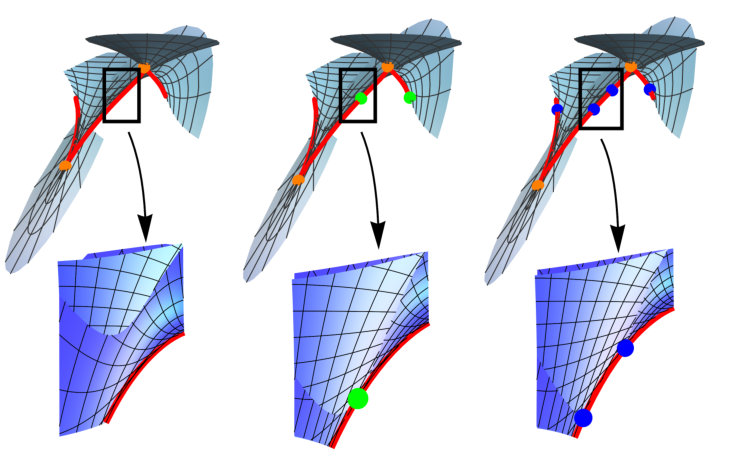 Figure 7
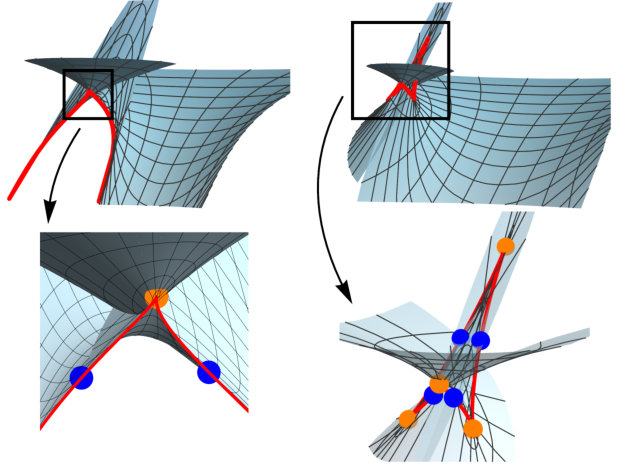 Figure 8
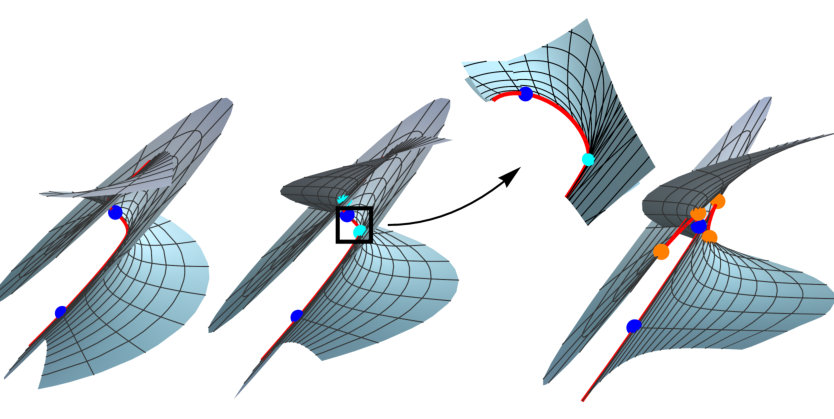 Figure 9
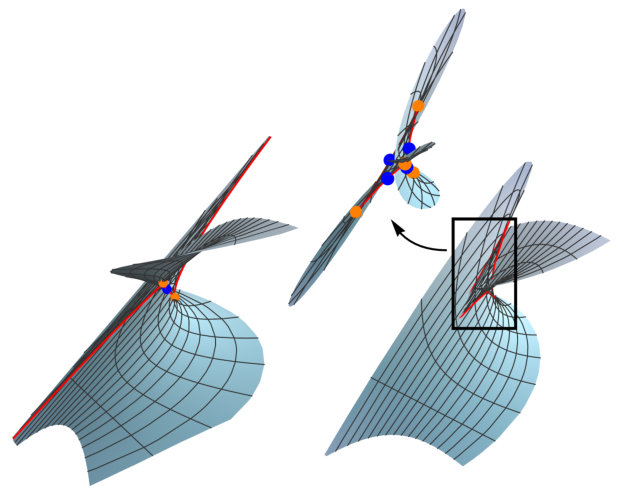 Figure 10
Peer Reviews
No public reviews on file for this paper yet. If you reviewed it on a platform where reviews are public (OpenReview, ICLR, NeurIPS, ICML), you can paste yours below so the community can read it here.
Videos
No videos yet. Explain this paper in a talk, walkthrough, or lecture? Add one.
Deformation and singularities of maximal surfaces with planar curvature lines
Joseph Cho
Department of mathematics, Faculty of science
Kobe university
Rokkodai-cho 1-1, Nada-ku, Kobe-shi, Hyogo-ken, 657-8501
Japan
and
Yuta Ogata
Department of Science and Technology
National Institute of Technology, Okinawa College
Henoko 905, Nago-shi
Okinawa-ken, 905-2171 Japan
Abstract.
Minimal surfaces with planar curvature lines in the Euclidean space have been studied since the late 19th century. On the other hand, the classification of maximal surfaces with planar curvature lines in the Lorentz-Minkowski space has only recently been given. In this paper, we use an alternative method not only to refine the classification of maximal surfaces with planar curvature lines, but also to show that there exists a deformation consisting exactly of all such surfaces. Furthermore, we investigate the types of singularities that occur on maximal surfaces with planar curvature lines. Finally, by considering the conjugate of maximal surfaces with planar curvature lines, we obtain analogous results for maximal surfaces that are also affine minimal surfaces.
Key words and phrases:
maximal surface, planar curvature line, singularity.
2010 Mathematics Subject Classification:
Primary 53A10; Secondary 57R45.
1. Introduction
Minimal surfaces with planar curvature lines in the Euclidean space have been studied extensively since the late 19th century by the likes of Bonnet, Enneper, and Eisenhart [7, 11, 10]. In his book, Nitsche summarized the result, that minimal surfaces with planar curvature lines must be a piece of one, and only one, of either the plane, Enneper surface, catenoid, or a surface in the Bonnet family [19]. Furthermore, many works have been published concerning minimal surfaces with spherical curvature lines, treating planes as spheres with infinite radius [9, 28].
On the other hand, the classification of maximal surfaces with planar curvature lines in Lorentz-Minkowski space has not been given until recently [17]. Leite developed an approach using orthogonal systems of cycles on the hyperbolic 2-space , and used the fact that families of planar curvature lines transform into orthogonal families of cycles on under its analogue of the Gauss map. Then she obtained the data for the following Weierstrass-type representation for maximal surfaces as first stated in [15], later refined to include singularities in [24].
Fact 1** (Weierstrass-type representation theorem for maximal surfaces).**
Any conformal maximal surface can be locally represented as
[TABLE]
over a simply-connected domain on which is meromorphic, while and are holomorphic.
(We note here that for a conformal maximal surface with Weierstrass data , one obtains the associated family of maximal surfaces via Weierstrass data for .) Using the above representation, Leite produced the following classification and their respective Weierstrass data .
Fact 2** ([17]).**
A maximal surface in Lorentz-Minkowski space with planar curvature lines must be a piece of one, and only one of
plane, with Weierstrass data ,
Enneper surface of first kind, with Weierstrass data ,
Enneper surface of second kind, with Weierstrass data , or one member of its associated family,
catenoid of first kind, with Weierstrass data ,
catenoid of second kind, with Weierstrass data , or
one surface in the Bonnet family, with Weierstrass data
up to isometries and homotheties of .
To study maximal surfaces with planar curvature lines, we start by proposing an alternative method to using Leite’s method. In Section 2, we closely follow the method used in [8], which was modeled after techniques used in [1], [2], [25], and [28]. First, we obtain and solve a system of partial differential equations for the metric function using the zero mean curvature condition and the planar curvature line condition. Then, from the metric function, we find the normal vector to the surface by using the notion of axial directions. From the normal vector, we recover the Weierstrass data and the parametrizations of maximal surfaces with planar curvature lines, allowing us to obtain a complete classification (see Theorem 2).
In fact, the axial directions play a crucial role in this paper, as they allow us not only to further classify maximal Bonnet-type surfaces into three types, but also to attain deformations consisting of the surfaces under consideration. In Section 3, we investigate those deformations, and show that there exists a single continuous deformation consisting exactly of the maximal surfaces with planar curvature lines (see Theorem 3, Fig. 4, and Fig. 5).
On the other hand, the notion of maxfaces as maximal surfaces in with singularities was introduced in [24], and various types of singularities appearing on maximal surfaces have been studied in various works [16, 12, 24, 14, 13, 21]. Since the singularities of maximal catenoids and the maximal Enneper-type surface were investigated in [16, 24, 13], in Section 4, we recognize the types of singularities for maximal Bonnet-type surfaces using the criteria introduced in [24], [13], and [21], and specify the types of singularities appearing in maximal surfaces with planar curvature lines (see Theorem 4, Fig. 6, and Fig. 7).
Finally in Section 5, we apply the results in Section 3 and Section 4 to maximal surfaces that are also affine minimal surfaces. Thomsen studied minimal surfaces in that are also affine minimal surfaces, and mentioned that such surfaces are conjugate surfaces of minimal surfaces with planar curvature lines [23]. Manhart has shown that the analogous result holds true for the maximal case in [18], and we use that result to consider the deformations and singularities of maximal surfaces that are also affine minimal surfaces (see Corollary 5.1, Corollary 5.2, Fig. 8, and Fig. 9).
2. Classification of maximal surfaces with planar curvature lines
In this section, we would like to obtain a complete classification of maximal surfaces with planar curvature lines by using the Weierstrass-type representation. We use an alternative method to orthogonal systems of cycles to recover the Weierstrass data as follows: First, from the zero mean curvature condition and planar curvature line condition, we obtain and solve a system of partial differential equations for the metric function. Then using the explicit solutions for the metric function, we recover the Weierstrass data and the parametrization by calculating the unit normal vector.
2.1. Maximal surface theory
Let be Lorentz-Minkowski space with Lorentzian metric
[TABLE]
In addition, let be a simply-connected domain with coordinates . Throughout the paper, we identify with the set of complex numbers via where . Let be a conformally immersed spacelike surface. Since is conformal, the induced metric is represented as
[TABLE]
for some function , where is the set of positive real numbers.
We choose the timelike unit normal vector field of , where is the two-sheeted hyperboloid in (cf. [24, (1.2)]), i.e.
[TABLE]
for
[TABLE]
Now, let be a non-planar umbilic-free maximal surface on the domain . By [6, Lemma 2.3.2] (see also [4, 5]), we may then further assume that are conformal curvature line (or isothermic) coordinates, and that the Hopf differential factor
[TABLE]
without loss of generality. Hence, the Gauss-Weingarten equations for the maximal case are the following:
[TABLE]
while the integrability condition, or the Gauss equation, becomes
[TABLE]
where . Finally, changing for , we obtain the associated family of . In particular, if then the new surface is called the conjugate of the original surface.
2.2. The planar curvature condition and analytic classification
Now, we impose the planar curvature line condition on a maximal surface. First, we consider the relationship between the planar curvature line condition and the metric function.
Lemma 2.1**.**
For a non-planar umbilic-free maximal surface , the following statements are equivalent:
- (1)
-curvature lines are planar. 2. (2)
-curvature lines are planar. 3. (3)
.
Proof.
Similar to the proof of Lemma 2.1 of [8], we can show this by calculating the conditions and using (2.1). ∎
Therefore, finding all non-planar umbilic-free maximal surfaces with planar curvature lines is equivalent to finding solutions to the following system of partial differential equations:
[TABLE]
To solve the above system, we note that (2.2a) and (2.2b) can be reduced to a system of ordinary differential equations as follows.
Lemma 2.2**.**
For a solution to (2.2a) and (2.2b), there exist real-valued functions and such that
[TABLE]
Furthermore, can be explicitly written in terms of and as follows:
**Case (1):: **
If is nowhere zero on ,
[TABLE]
where and satisfy the following system of ordinary differential equations:
[TABLE]
for real constants and such that .
**Case (2):: **
If on , i.e. is identically zero on ,
[TABLE]
where and for some constant .
Proof.
Arguments to prove (2.3a), (2.3b), (2.4), and (2.5a)–(2.5d) are similar to those in the proof of Lemma 2.2 in [8]; here we only give a short outline of these arguments.
Integrating (2.2b) once with respect to and once with respect to gives (2.3a) and (2.3b). Now first assume that is not identically equal to zero. Then we can choose a point such that , implying that we can choose a neighborhood of such that is nowhere zero on . On such , we can use (2.2a) with (2.3a) and (2.3b) to obtain (2.4). Finally, using (2.3a) and (2.3b) with (2.4) and integrating with respect to and , respectively, we obtain (2.5a)–(2.5d).
Now assume that is identically equal to zero on some simply-connected domain . Since , for all and . This implies that both and are constant, and we can set and for some constant . Solving (2.3a) and (2.3b), we obtain (2.6). ∎
We would now like to solve for and satisfying (2.5a)–(2.5d) in Case (1). First, assume that . Then (2.5a) and (2.5c) imply that and that
[TABLE]
for some real constants of integration and . Now assuming that , we can explicitly solve for and to find that
[TABLE]
where are constants of integration. Furthermore since and are real-valued functions, must satisfy
[TABLE]
where denotes the complex conjugation.
To explicitly solve for and and hence , we first need to consider the initial conditions of and . We identify the exact conditions for and having a zero, and derive the appropriate initial conditions in the following series of lemmas.
Lemma 2.3**.**
* (resp. ) satisfying (2.5a)–(2.5d) has a zero if and only if either or (resp. or ).*
Proof.
If , then the statement is trivial by (2.7); hence, we may assume . To prove the necessary condition, since case is trivial, assume that , and we show that there is some real such that . If , then it is easy to check that for
[TABLE]
we get by (2.8).
Now assume . Then since
[TABLE]
we may write and for some constant . By letting
[TABLE]
we have again by (2.8).
To show the sufficient condition, suppose there is some such that . By (2.5a), . If , then, (2.8) gives us
[TABLE]
for some complex constants and where . Since , without loss of generality, let . From , we get . Therefore, , and we have .
The statement regarding is proven analogously. ∎
Lemma 2.4**.**
* (resp. ) has no zero if and only if either or where (resp. or where ).*
Proof.
Note that by the previous lemma and the fact that implies , we only need to show that and if and only if for and .
First, suppose that and . Then, similar to the proof of the previous lemma,
[TABLE]
for some complex constant . Since , . In addition, since is real, is real, and . Finally, by shifting parameters, we may assume that .
Now assume that for . Then trivially. Furthermore, (2.5b) implies that for all . Hence, . ∎
Lemma 2.5**.**
At least one of or must have a zero.
Proof.
Without loss of generality, suppose that does not have a zero. Hence, by the previous lemma, or where . If with , must have a zero by Lemma 2.3.
Now suppose . Then, by (2.5a), . If , then (2.5c) implies , a contradiction; hence, . If , direct calculation shows that either or where and . However, since we assumed , it must follow that or . Hence, must have a zero. ∎
Exchanging the roles of and , if necessary, we may assume without loss of generality that has a zero, and we may further assume that by shifting parameters. By considering the fact that we may switch the roles of and , we only need to consider the following five cases:
[TABLE]
It should be noted that in the cases considered (2.9), , and that if and only if . For the third case, since , By letting , we see that the plus or minus condition on may be dropped, allowing us to assume that . Finally, we prove the following statement regarding the initial condition of .
Lemma 2.6**.**
For the cases (2.9), there is some such that .
Proof.
It is easy to check that the statement holds if via (2.7); hence, assume . From (2.8), since implies and are non-zero, we let
[TABLE]
If , then since , is real-valued such that . Since implies that , assume and . Then direct calculation shows that is the complex conjugate of implying that is equal to its own conjugate. Therefore, is real-valued such that . ∎
Therefore, through shifting parameters, we may assume that and . Using these initial conditions, we arrive at the following explicit solutions for and .
Proposition 2.1**.**
For a non-planar maxface with planar curvature lines, the real-analytic solution of (2.2a) and (2.2b) is precisely given as follows:
**Case (1): **
If , i.e. is not identically equal to zero, then
[TABLE]
with
[TABLE]
where and .
**Case (2): **
If , then for some constant such that ,
[TABLE]
Proof.
Solving (2.5a)–(2.5d) for and with initial conditions and , and considering the change in parameter or , if necessary, gives the explicit solutions in (2.10).
Now we wish to see that the domain of can be extended to globally. If , then this is a direct result of applying the solution in (2.10). Therefore, assume . Then by (2.5a) and (2.5c), we have
[TABLE]
implying that
[TABLE]
Therefore, the real-analyticity of and implies that the domain of can be extended to globally. ∎
Remark 1*.*
We make a few important remarks about Proposition 2.1:
In the statement of Proposition 2.1, we now allow to map into as opposed to , i.e. may have zeroes, or even be negative. By doing so, we now consider as maxfaces, defined in [24] as a class of maximal surfaces with singularities (see also [13]).
In (2.10), we allow . However, even in such case, by using the identities
[TABLE]
we see that and are real-valued analytic functions.
For case (2) in Proposition 2.1, we may use an associated family’s parameter instead of through appropriate coordinate change shown below:
[TABLE]
However, it should be noted that while the coordinate change and parameter change preserve the conformal structure, it does not hold the curvature line coordinates such that .
Note that for all cases, the metric function is always bounded for all , and we now have the following theorem. Note that , used as a subscript in Figure 1, means the role of and are switched, up to shift of parameters.
Theorem 1**.**
Let be a non-planar maxface in with isothermic coordinates such that the induced metric . Then has planar curvature lines if and only if satisfies Proposition 2.1. Furthermore, for different values of or as in Remark 1, the surface has the following properties based on Fig. 1:
**Case (1): **
If , when lies on
- **: **
\raisebox{-.9pt} {1}⃝*: is not periodic in the -direction, but constant in the -direction,*
- **: **
, or \raisebox{-.9pt} {4}⃝: is not periodic in the -direction, but periodic in the -direction,
- **: **
\raisebox{-.9pt} {5}⃝*: is not periodic in both the -direction and the -direction,*
- **: **
\raisebox{-.9pt} {6}⃝*: is periodic in the -direction, but constant in the -direction.*
**Case (2): **
If , when lies on
- **: **
\raisebox{-.9pt} {7}⃝*: is a surface of revolution,*
- **: **
\raisebox{-.9pt} {8}⃝*: is a surface in the associated family of \raisebox{-.9pt} {7}⃝.*
2.3. Axial directions and normal vector
To find the parametrizations of the surfaces considered, we would like to recover the Weierstrass data from the metric function as follows: We first show the existence of a unique constant direction for surfaces under consideration called the axial direction, and use it to calculate the unit normal vector. Then from the unit normal vector, we recover the Weierstrass data. First, we show the existence of the axial direction in the following proposition.
Proposition 2.2**.**
If there exists (resp. ) such that (resp. ) in Proposition 2.1, then there exists a unique non-zero constant vector (resp. ) such that
[TABLE]
where (resp. ) and
[TABLE]
[TABLE]
If and both exist, then they are orthogonal to each other. We call and the axial directions of .
Proof.
Similar to the proof of Proposition 2.2 in [8]; here we only give an outline of the proof. Using (2.1), (2.2a) and (2.2b), we may calculate that all the required property holds. ∎
Since and are constant, we use (2.2a), (2.2b), (2.4), and (2.5a)–(2.5d) to calculate that
[TABLE]
implying that the axial directions of the surface has the following causalities: if ,
both and are spacelike if ,
is lightlike, but is spacelike if , or
is timelike, but is spacelike if .
Note that if , then , implying that does not exist. By aligning the axial directions with coordinate axes of the ambient space, we now calculate the unit normal vector.
First, assume . Since the definition of and depend on the signature of , we consider each case separately.
2.3.1. Case (1a)
Assume first that (see left side of Fig. 2). Then and are both spacelike, and we align the axial directions so that and are parallel to and , respectively, where are the unit vectors in the -direction for . Then, we may calculate the unit normal vector as follows.
Lemma 2.7**.**
Let be the unit normal vector to the surface satisfying case (1) of Proposition 2.1. If , then, the unit normal vector is given by
[TABLE]
Proof.
Similar to the proof of Proposition 2.3 in [8]; we use the fact that and in Proposition 2.2, and the fact that . ∎
Now, let and for (see left side of Fig. 2). Since is a homothety factor of domain -plane by (2.10), we may assume . Using the above lemma, we may find the normal vector dependent on . On the other hand, since the meromorphic function of the Weierstrass data is equal to the normal vector function under stereographic projection, and since ,
[TABLE]
Therefore, using , we calculate that for ,
[TABLE]
where , , and .
2.3.2. Case (1b)
Now assume that (see right side of Fig. 2). Then, since the causality of changes while that of is always spacelike, we let
[TABLE]
for some real constants and , while we let be parallel to . To calculate the unit normal vector for this case, we first need the following lemma.
Lemma 2.8**.**
Let be the unit normal vector to the surface satisfying case (1) of Proposition 2.1. If , then
[TABLE]
where and are as in (2.14).
Proof.
Employing similar techniques to those used in the proof of Proposition 2.3 in [8] and Lemma 2.7 implies that
[TABLE]
for some constant . To find in (2.16), consider the following system of equations,
[TABLE]
where the first equation comes from (2.1), (2.11), and (2.12). Since is constant, we may solve for at the point to get (2.15). ∎
Since is unit length, (2.15) lets us calculate the normal of the surface for any given , , , and . Similar to the previous case, let and for , and further let
[TABLE]
Now, we calculate the normal vector, and find that for ,
[TABLE]
where and .
2.3.3. Case (2)
Finally, we consider the case when . By Remark 1, we only need to consider , and then utilize the parameter for the associated family for . First we assume that the lightlike axis . Then similar to the previous cases,
[TABLE]
for some real constant . By applying the scaling of , without loss of generality, we can assume . Now since is independent of , we notice that has the form of for a specific isometry transform keeping the lightlike axis . Thus we get the following:
Lemma 2.9**.**
For case (2) in Proposition 2.1, the unit normal vector of is given by
[TABLE]
Using the above proposition, we obtain the following Weierstrass data, up to the homothety of domain:
[TABLE]
By changing data , we get all maxfaces in case (2) with parameter .
Since the data obtained all satisfy the meromorphicity and holomorphicity conditions, we may use the Weierstrass-type representation for maxfaces to obtain the following parametrizations.
Theorem 2**.**
If is a non-planar maxface with planar curvature lines in , then the surface is given by the following parametrization on its domain for some :
[TABLE]
where is given by and , and
[TABLE]
or for some ,
[TABLE]
up to isometries and homotheties of . In fact, it must be a piece of one, and only one, of the following:
maximal Enneper-type surface (E) with Weierstrass data , ,
maximal catenoid with lightlike axis (CL) with Weierstrass data , or a member of its associated family ,
*maximal catenoid with spacelike axis (CS) with Weierstrass data *
, ,
maximal catenoid with timelike axis (CT) with Weierstrass data , ,
*maximal Bonnet-type surface with lightlike axial direction (BL) with Weierstrass data *
, ,
maximal Bonnet-type surface with spacelike axial direction (BS) with Weierstrass data
[TABLE]
or maximal Bonnet-type surface with timelike axial direction (BT) with Weierstrass data
[TABLE]
Moreover, is continuous at every point with respect to the parameter .
Note that by (2.12), we see that the different classes of maximal Bonnet-type surfaces mentioned in [17] have a geometric meaning; namely, the causal character of the axial directions are different. Finally, it should be noted that a catenoid with timelike axis is indeed a limiting case of maximal Bonnet-type surfaces with timelike axial direction, while a catenoid with spacelike axis is a limiting case of maximal Bonnet-type surfaces with spacelike axial direction.
3. Continuous deformation of maximal surfaces with planar curvature lines
Now, we show that all maxfaces with planar curvature lines can be conjoined by a single continuous deformation. However, as seen in the previous section, the Weierstrass data and the parametrizations of such surfaces depended on two separate parameters and . Therefore, we need to show that there exists a deformation consisting of maxfaces with planar curvature lines that connects the surfaces in each parameter family. In addition, it must be verified that the plane can also be attained as a limit of such surfaces.
Therefore, in this section, we explain how all the maxfaces with planar curvature lines can be joined by a series of continuous deformations. We consider a deformation to be “continuous” with respect to a parameter, if the deformation dependent on the parameter converges uniformally over compact subdomains component-wise. In fact, it will be enough to show that each component function in the parametrization is continuous for the parameter at any point in the domain.
3.1. Deformation to the maximal catenoid with lightlike axis
First, we will show that there exists a deformation between a maximal Bonnet-type surface with lightlike axial direction and a maximal catenoid with lightlike axis. Assume and (see Fig. 3). Then by (2.12), is a lightlike axial direction while is a spacelike axial direction. Therefore, align the vectors as and .
Then by Lemma 2.8, , and where . Again using the unit normal vector, we calculate the following Weierstrass data:
[TABLE]
Note that
[TABLE]
In addition, by using the Weierstrass-type representation theorem,
[TABLE]
for . Since
[TABLE]
is a continuous deformation from maximal Bonnet-type surface with lightlike axial direction (BL) to the maximal catenoid with lightlike axis (CL) (or maximal Enneper-type surface of second kind).
3.2. Deformation to the plane
Now, we show that there exists a deformation connecting maximal catenoid with spacelike axis to the plane. Up to this point, to solve the system of ordinary differential equations (2.5a)–(2.5d), we assumed that , and . However, since for the plane, we must consider different initial conditions for and . Therefore, we use the result from Lemma 2.3 and consider the surfaces corresponding to case (1a), to assume that and . Solving (2.5a)–(2.5d) similarly, we get
[TABLE]
where .
Since we assumed each of and has a zero, both axial directions are spacelike, and we may use Lemma 2.7 to calculate the unit normal vector. After letting and , we calculate the Weierstrass data as
[TABLE]
for , where the factor for shifting parameter was chosen so that
[TABLE]
Using the Weierstrass-type representation theorem, and multiplying by a homothety factor , we find that
[TABLE]
for , where . Since
[TABLE]
defines a continuous deformation from the maximal catenoid with spacelike axis (CS) to the plane (P). In summary, we get the following theorem.
Theorem 3**.**
There exists a continuous deformation consisting precisely of the maxfaces with planar curvature lines (see Fig. 4 and Fig. 5).
4. Singularities of maximal Bonnet-type surfaces
As mentioned in Remark 1, maxfaces was introduced as a class of maximal surfaces with singularities in [24]. In this section, we investigate the types of singularities appearing on maxfaces with planar curvature lines. Since the types of singularities of maximal catenoids and maximal Enneper-type surfaces have been investigated [16, 24, 13], we focus on recognizing the types of singularities on maximal Bonnet-type surfaces.
Let be the singular set. Then using the explicit solution of the metric function in Proposition 2.1, we understand that the singular set becomes -dimensional. To recognize the types of singularities of maximal Bonnet-type surfaces, we refer to the following results from [24], [13], and [21].
Fact 3**.**
Let be a maxface with Weierstrass data . Then, a point is a singular point if and only if . Furthermore, for
[TABLE]
the image of around a singular point is locally diffeomorphic to
a cuspidal edge if and only if and at ,
a swallowtail if and only if and at ,
a cuspidal cross cap if and only if and at , or
a cuspidal singularity if and only if , , and at .
To make the calculations simpler, from Lemma 2.8, assume that and for . If we further assume that and , then we obtain the following Weierstrass data:
[TABLE]
after a shift of paramter . Note that this Weierstrass data represents exactly the Bonnet family described in [17], and that all maximal Bonnet-type surfaces are included in this family by Theorem 1. Then, for the family,
If , the surface is a maximal Bonnet-type surface with spacelike axial direction.
If , the surface is a maximal Bonnet-type surface with lightlike axial direction.
If , the surface is a maximal Bonnet-type surface with timelike axial direction.
By directly calculating , , and , and using Fact 3, we arrive at the following result.
Proposition 4.1**.**
Let be a maximal Bonnet-type surface with the Weierstrass data given in (4.1). The image of around a singular point is locally diffeomorphic to the following:
a swallowtail (SW) only at
[TABLE]
a cuspidal cross cap (CCR) only at
[TABLE]
or a cuspidal singularity (CS) only at
[TABLE]
where \mathbin{\mathchoice{\leavevmode\hbox to12.42pt{\vbox to12.42pt{\pgfpicture\makeatletter\hbox{\hskip 6.20927pt\lower-6.20927pt\hbox to0.0pt{\pgfsys@beginscope\pgfsys@invoke{ }\definecolor{pgfstrokecolor}{rgb}{0,0,0}\pgfsys@color@rgb@stroke{0}{0}{0}\pgfsys@invoke{ }\pgfsys@color@rgb@fill{0}{0}{0}\pgfsys@invoke{ }\pgfsys@setlinewidth{0.4pt}\pgfsys@invoke{ }\nullfont\hbox to0.0pt{\pgfsys@beginscope\pgfsys@invoke{ } {{}}\hbox{\hbox{{\pgfsys@beginscope\pgfsys@invoke{ }{{}{{{}}}{{}}{}{}{}{}{}{}{}{}{}{{}\pgfsys@moveto{6.00928pt}{0.0pt}\pgfsys@curveto{6.00928pt}{3.31886pt}{3.31886pt}{6.00928pt}{0.0pt}{6.00928pt}\pgfsys@curveto{-3.31886pt}{6.00928pt}{-6.00928pt}{3.31886pt}{-6.00928pt}{0.0pt}\pgfsys@curveto{-6.00928pt}{-3.31886pt}{-3.31886pt}{-6.00928pt}{0.0pt}{-6.00928pt}\pgfsys@curveto{3.31886pt}{-6.00928pt}{6.00928pt}{-3.31886pt}{6.00928pt}{0.0pt}\pgfsys@closepath\pgfsys@moveto{0.0pt}{0.0pt}\pgfsys@stroke\pgfsys@invoke{ } }{{{{}}\pgfsys@beginscope\pgfsys@invoke{ }\pgfsys@transformcm{1.0}{0.0}{0.0}{1.0}{-4.99998pt}{-2.5pt}\pgfsys@invoke{ }\hbox{{\definecolor{pgfstrokecolor}{rgb}{0,0,0}\pgfsys@color@rgb@stroke{0}{0}{0}\pgfsys@invoke{ }\pgfsys@color@rgb@fill{0}{0}{0}\pgfsys@invoke{ }\hbox{{\displaystyle\pm}} }}\pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope}}} \pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope}}} \pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope{{{}}}{}{}\hss}\pgfsys@discardpath\pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope\hss}}\lxSVG@closescope\endpgfpicture}}}{\leavevmode\hbox to12.42pt{\vbox to12.42pt{\pgfpicture\makeatletter\hbox{\hskip 6.20927pt\lower-6.20927pt\hbox to0.0pt{\pgfsys@beginscope\pgfsys@invoke{ }\definecolor{pgfstrokecolor}{rgb}{0,0,0}\pgfsys@color@rgb@stroke{0}{0}{0}\pgfsys@invoke{ }\pgfsys@color@rgb@fill{0}{0}{0}\pgfsys@invoke{ }\pgfsys@setlinewidth{0.4pt}\pgfsys@invoke{ }\nullfont\hbox to0.0pt{\pgfsys@beginscope\pgfsys@invoke{ } {{}}\hbox{\hbox{{\pgfsys@beginscope\pgfsys@invoke{ }{{}{{{}}}{{}}{}{}{}{}{}{}{}{}{}{{}\pgfsys@moveto{6.00928pt}{0.0pt}\pgfsys@curveto{6.00928pt}{3.31886pt}{3.31886pt}{6.00928pt}{0.0pt}{6.00928pt}\pgfsys@curveto{-3.31886pt}{6.00928pt}{-6.00928pt}{3.31886pt}{-6.00928pt}{0.0pt}\pgfsys@curveto{-6.00928pt}{-3.31886pt}{-3.31886pt}{-6.00928pt}{0.0pt}{-6.00928pt}\pgfsys@curveto{3.31886pt}{-6.00928pt}{6.00928pt}{-3.31886pt}{6.00928pt}{0.0pt}\pgfsys@closepath\pgfsys@moveto{0.0pt}{0.0pt}\pgfsys@stroke\pgfsys@invoke{ } }{{{{}}\pgfsys@beginscope\pgfsys@invoke{ }\pgfsys@transformcm{1.0}{0.0}{0.0}{1.0}{-4.99998pt}{-2.5pt}\pgfsys@invoke{ }\hbox{{\definecolor{pgfstrokecolor}{rgb}{0,0,0}\pgfsys@color@rgb@stroke{0}{0}{0}\pgfsys@invoke{ }\pgfsys@color@rgb@fill{0}{0}{0}\pgfsys@invoke{ }\hbox{{\textstyle\pm}} }}\pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope}}} \pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope}}} \pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope{{{}}}{}{}\hss}\pgfsys@discardpath\pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope\hss}}\lxSVG@closescope\endpgfpicture}}}{\leavevmode\hbox to9.36pt{\vbox to9.36pt{\pgfpicture\makeatletter\hbox{\hskip 4.68071pt\lower-4.68071pt\hbox to0.0pt{\pgfsys@beginscope\pgfsys@invoke{ }\definecolor{pgfstrokecolor}{rgb}{0,0,0}\pgfsys@color@rgb@stroke{0}{0}{0}\pgfsys@invoke{ }\pgfsys@color@rgb@fill{0}{0}{0}\pgfsys@invoke{ }\pgfsys@setlinewidth{0.4pt}\pgfsys@invoke{ }\nullfont\hbox to0.0pt{\pgfsys@beginscope\pgfsys@invoke{ } {{}}\hbox{\hbox{{\pgfsys@beginscope\pgfsys@invoke{ }{{}{{{}}}{{}}{}{}{}{}{}{}{}{}{}{{}\pgfsys@moveto{4.48071pt}{0.0pt}\pgfsys@curveto{4.48071pt}{2.47466pt}{2.47466pt}{4.48071pt}{0.0pt}{4.48071pt}\pgfsys@curveto{-2.47466pt}{4.48071pt}{-4.48071pt}{2.47466pt}{-4.48071pt}{0.0pt}\pgfsys@curveto{-4.48071pt}{-2.47466pt}{-2.47466pt}{-4.48071pt}{0.0pt}{-4.48071pt}\pgfsys@curveto{2.47466pt}{-4.48071pt}{4.48071pt}{-2.47466pt}{4.48071pt}{0.0pt}\pgfsys@closepath\pgfsys@moveto{0.0pt}{0.0pt}\pgfsys@stroke\pgfsys@invoke{ } }{{{{}}\pgfsys@beginscope\pgfsys@invoke{ }\pgfsys@transformcm{1.0}{0.0}{0.0}{1.0}{-3.83331pt}{-1.75pt}\pgfsys@invoke{ }\hbox{{\definecolor{pgfstrokecolor}{rgb}{0,0,0}\pgfsys@color@rgb@stroke{0}{0}{0}\pgfsys@invoke{ }\pgfsys@color@rgb@fill{0}{0}{0}\pgfsys@invoke{ }\hbox{{\scriptstyle\pm}} }}\pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope}}} \pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope}}} \pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope{{{}}}{}{}\hss}\pgfsys@discardpath\pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope\hss}}\lxSVG@closescope\endpgfpicture}}}{\leavevmode\hbox to7.35pt{\vbox to7.35pt{\pgfpicture\makeatletter\hbox{\hskip 3.67632pt\lower-3.67632pt\hbox to0.0pt{\pgfsys@beginscope\pgfsys@invoke{ }\definecolor{pgfstrokecolor}{rgb}{0,0,0}\pgfsys@color@rgb@stroke{0}{0}{0}\pgfsys@invoke{ }\pgfsys@color@rgb@fill{0}{0}{0}\pgfsys@invoke{ }\pgfsys@setlinewidth{0.4pt}\pgfsys@invoke{ }\nullfont\hbox to0.0pt{\pgfsys@beginscope\pgfsys@invoke{ } {{}}\hbox{\hbox{{\pgfsys@beginscope\pgfsys@invoke{ }{{}{{{}}}{{}}{}{}{}{}{}{}{}{}{}{{}\pgfsys@moveto{3.47632pt}{0.0pt}\pgfsys@curveto{3.47632pt}{1.91994pt}{1.91994pt}{3.47632pt}{0.0pt}{3.47632pt}\pgfsys@curveto{-1.91994pt}{3.47632pt}{-3.47632pt}{1.91994pt}{-3.47632pt}{0.0pt}\pgfsys@curveto{-3.47632pt}{-1.91994pt}{-1.91994pt}{-3.47632pt}{0.0pt}{-3.47632pt}\pgfsys@curveto{1.91994pt}{-3.47632pt}{3.47632pt}{-1.91994pt}{3.47632pt}{0.0pt}\pgfsys@closepath\pgfsys@moveto{0.0pt}{0.0pt}\pgfsys@stroke\pgfsys@invoke{ } }{{{{}}\pgfsys@beginscope\pgfsys@invoke{ }\pgfsys@transformcm{1.0}{0.0}{0.0}{1.0}{-3.05553pt}{-1.25pt}\pgfsys@invoke{ }\hbox{{\definecolor{pgfstrokecolor}{rgb}{0,0,0}\pgfsys@color@rgb@stroke{0}{0}{0}\pgfsys@invoke{ }\pgfsys@color@rgb@fill{0}{0}{0}\pgfsys@invoke{ }\hbox{{\scriptscriptstyle\pm}} }}\pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope}}} \pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope}}} \pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope{{{}}}{}{}\hss}\pgfsys@discardpath\pgfsys@invoke{\lxSVG@closescope }\pgfsys@endscope\hss}}\lxSVG@closescope\endpgfpicture}}}} corresponds to each other.
Hence, from the singularity theory point of view, we understand that maximal Bonnet-type surfaces with timelike axial directions can further be classified into the following three types: type 1 (BT1), type 2 (BT2), or type 3 (BT3).
Since maximal Bonnet-type surfaces are periodic in the -direction, let a single portion of refer to the part of the surface mapped over a single period of in the domain. Then, in summary, we understand the following theorem concerning the types of singularities on maximal Bonnet-type surfaces.
Theorem 4**.**
Let be a maximal Bonnet-type surface with the Weierstrass data given in (4.1). The images of a single portion of around singular points are locally diffeomorphic to cuspidal edges except at the following number of points.
[TABLE]
Combined with the result in [16], [24], and [13], we obtain the following corollary.
Corollary**.**
Let be a maxface with planar curvature lines. If is a singular point of , then the image of around the singular point must be locally diffeomorphic to one of the following: conelike singularity, fold singularity, cuspidal edge, swallowtail, cuspidal cross cap, or cuspidal singularity.
5. Maximal surfaces that are also affine minimal surfaces
In the Euclidean case, Thomsen studied minimal surfaces in that are also affine minimal surfaces, those surfaces with zero affine mean curvature surfaces and with indefinite affine metric with respect to the equiaffine structure, called Thomsen surfaces, in [23], and commented on the fact that such surfaces are conjugates of minimal surfaces with planar curvature lines. The analogous statement holds true for maximal surfaces in as shown through the following result in [18].
Fact 4**.**
An umbilic-free maximal surface in has planar curvature lines if and only if the conjugate surface is an affine minimal surface.
Therefore, by considering the conjugate surfaces of maximal surfaces with planar curvature lines, we get the following result from Theorem 3.
Corollary 5.1** (Corollary to Theorem 3).**
There exists a continuous deformation consisting precisely of the maximal surfaces that are also affine minimal surfaces.
Furthermore, by the duality of singularities between conjugate surfaces explored in [24], [14], [13], and [21], we obtain the following classification of singularities on maximal Thomsen-type surfaces.
Corollary 5.2** (Corollary to Theorem 4).**
Let be a maximal Thomsen-type surface where is the conjugate surface of as defined in Theorem 4. The images of a single portion of around singular points are locally diffeomorphic to cuspidal edges except at the following number of points.
[TABLE]
where CB stands for cuspidal butterfly.
Moreover, if is a maximal surface that is also an affine minimal surface, then the image of around the singular point must be locally diffeomorphic to one of the following: conelike singularity, fold singularity, cuspidal edge, swallowtail, cuspidal cross cap, or cuspidal butterfly.
Acknowledgements. The authors express their gratitude to Professor Shoichi Fujimori, Professor Hitoshi Furuhata, Professor Wayne Rossman, Keisuke Teramoto, and the referee for many useful comments.
The reference list from the paper itself. Each links out to its DOI / PubMed record.
- 1Abresch [1987] U. Abresch. Constant mean curvature tori in terms of elliptic functions. J. Reine Angew. Math. , 374:169–192, 1987. ISSN 0075-4102. doi: 10.1515/crll.1987.374.169 . · doi ↗
- 2Barthel et al. [1980] W. Barthel, R. Volkmer, and I. Haubitz. Thomsensche Minimalflächen–analytisch und anschaulich. Resultate Math. , 3(2):129–154, 1980. ISSN 0378-6218.
- 3Blaschke [1923] W. Blaschke. Vorlesungen über Differentialgeometrie und geometrische Grundlagen von Einsteins Relativitätstheorie II: Affine Differentialgeometrie . Springer, Berlin, 1923. ISBN 978-3-642-47125-4.
- 4Bobenko [1990] A. I. Bobenko. Integrable surfaces. Funktsional. Anal. i Prilozhen. , 24(3):68–69, 1990. ISSN 0374-1990. doi: 10.1007/BF 01077966 . · doi ↗
- 5Bobenko [1991] A. I. Bobenko. Surfaces of constant mean curvature and integrable equations. Russian Math. Surveys , 46(4):1–45, 1991. ISSN 0042-1316. doi: 10.1070/RM 1991 v 046n 04ABEH 002826 . · doi ↗
- 6Bobenko and Eitner [2000] A. I. Bobenko and U. Eitner. Painlevé Equations in the Differential Geometry of Surfaces , volume 1753 of Lecture Notes in Mathematics . Springer-Verlag, Berlin, 2000. ISBN 978-3-540-41414-8. doi: 10.1007/b 76883 . · doi ↗
- 7Bonnet [1855] O. Bonnet. Observations sur les surfaces minima. C. R. Acad. Sci. Paris , 41:1057–1058, 1855.
- 8Cho and Ogata [2017] J. Cho and Y. Ogata. Deformation of minimal surfaces with planar curvature lines. J. Geom. , 108(2):463–479, 2017. doi: 10.1007/s 00022-016-0352-0 . · doi ↗