Sparse Recovery from Combined Fusion Frame Measurements
Petros T. Boufounos, Gitta Kutyniok, Holger Rauhut

TL;DR
This paper introduces a new sparsity model for fusion frames that enables efficient compressed sensing and exact reconstruction of signals sparse across subspaces, expanding the mathematical tools for signal processing.
Contribution
It proposes a novel sparsity model for fusion frames using a mixed l1/l2 norm, allowing for compressive sampling and exact recovery of signals with fewer measurements.
Findings
Sampling conditions generalize coherence and RIP in CS
Exact reconstruction guaranteed under new conditions
Recovery probability improves exponentially with subspace dimension
Abstract
Sparse representations have emerged as a powerful tool in signal and information processing, culminated by the success of new acquisition and processing techniques such as Compressed Sensing (CS). Fusion frames are very rich new signal representation methods that use collections of subspaces instead of vectors to represent signals. This work combines these exciting fields to introduce a new sparsity model for fusion frames. Signals that are sparse under the new model can be compressively sampled and uniquely reconstructed in ways similar to sparse signals using standard CS. The combination provides a promising new set of mathematical tools and signal models useful in a variety of applications. With the new model, a sparse signal has energy in very few of the subspaces of the fusion frame, although it does not need to be sparse within each of the subspaces it occupies. This sparsity…
Click any figure to enlarge with its caption.
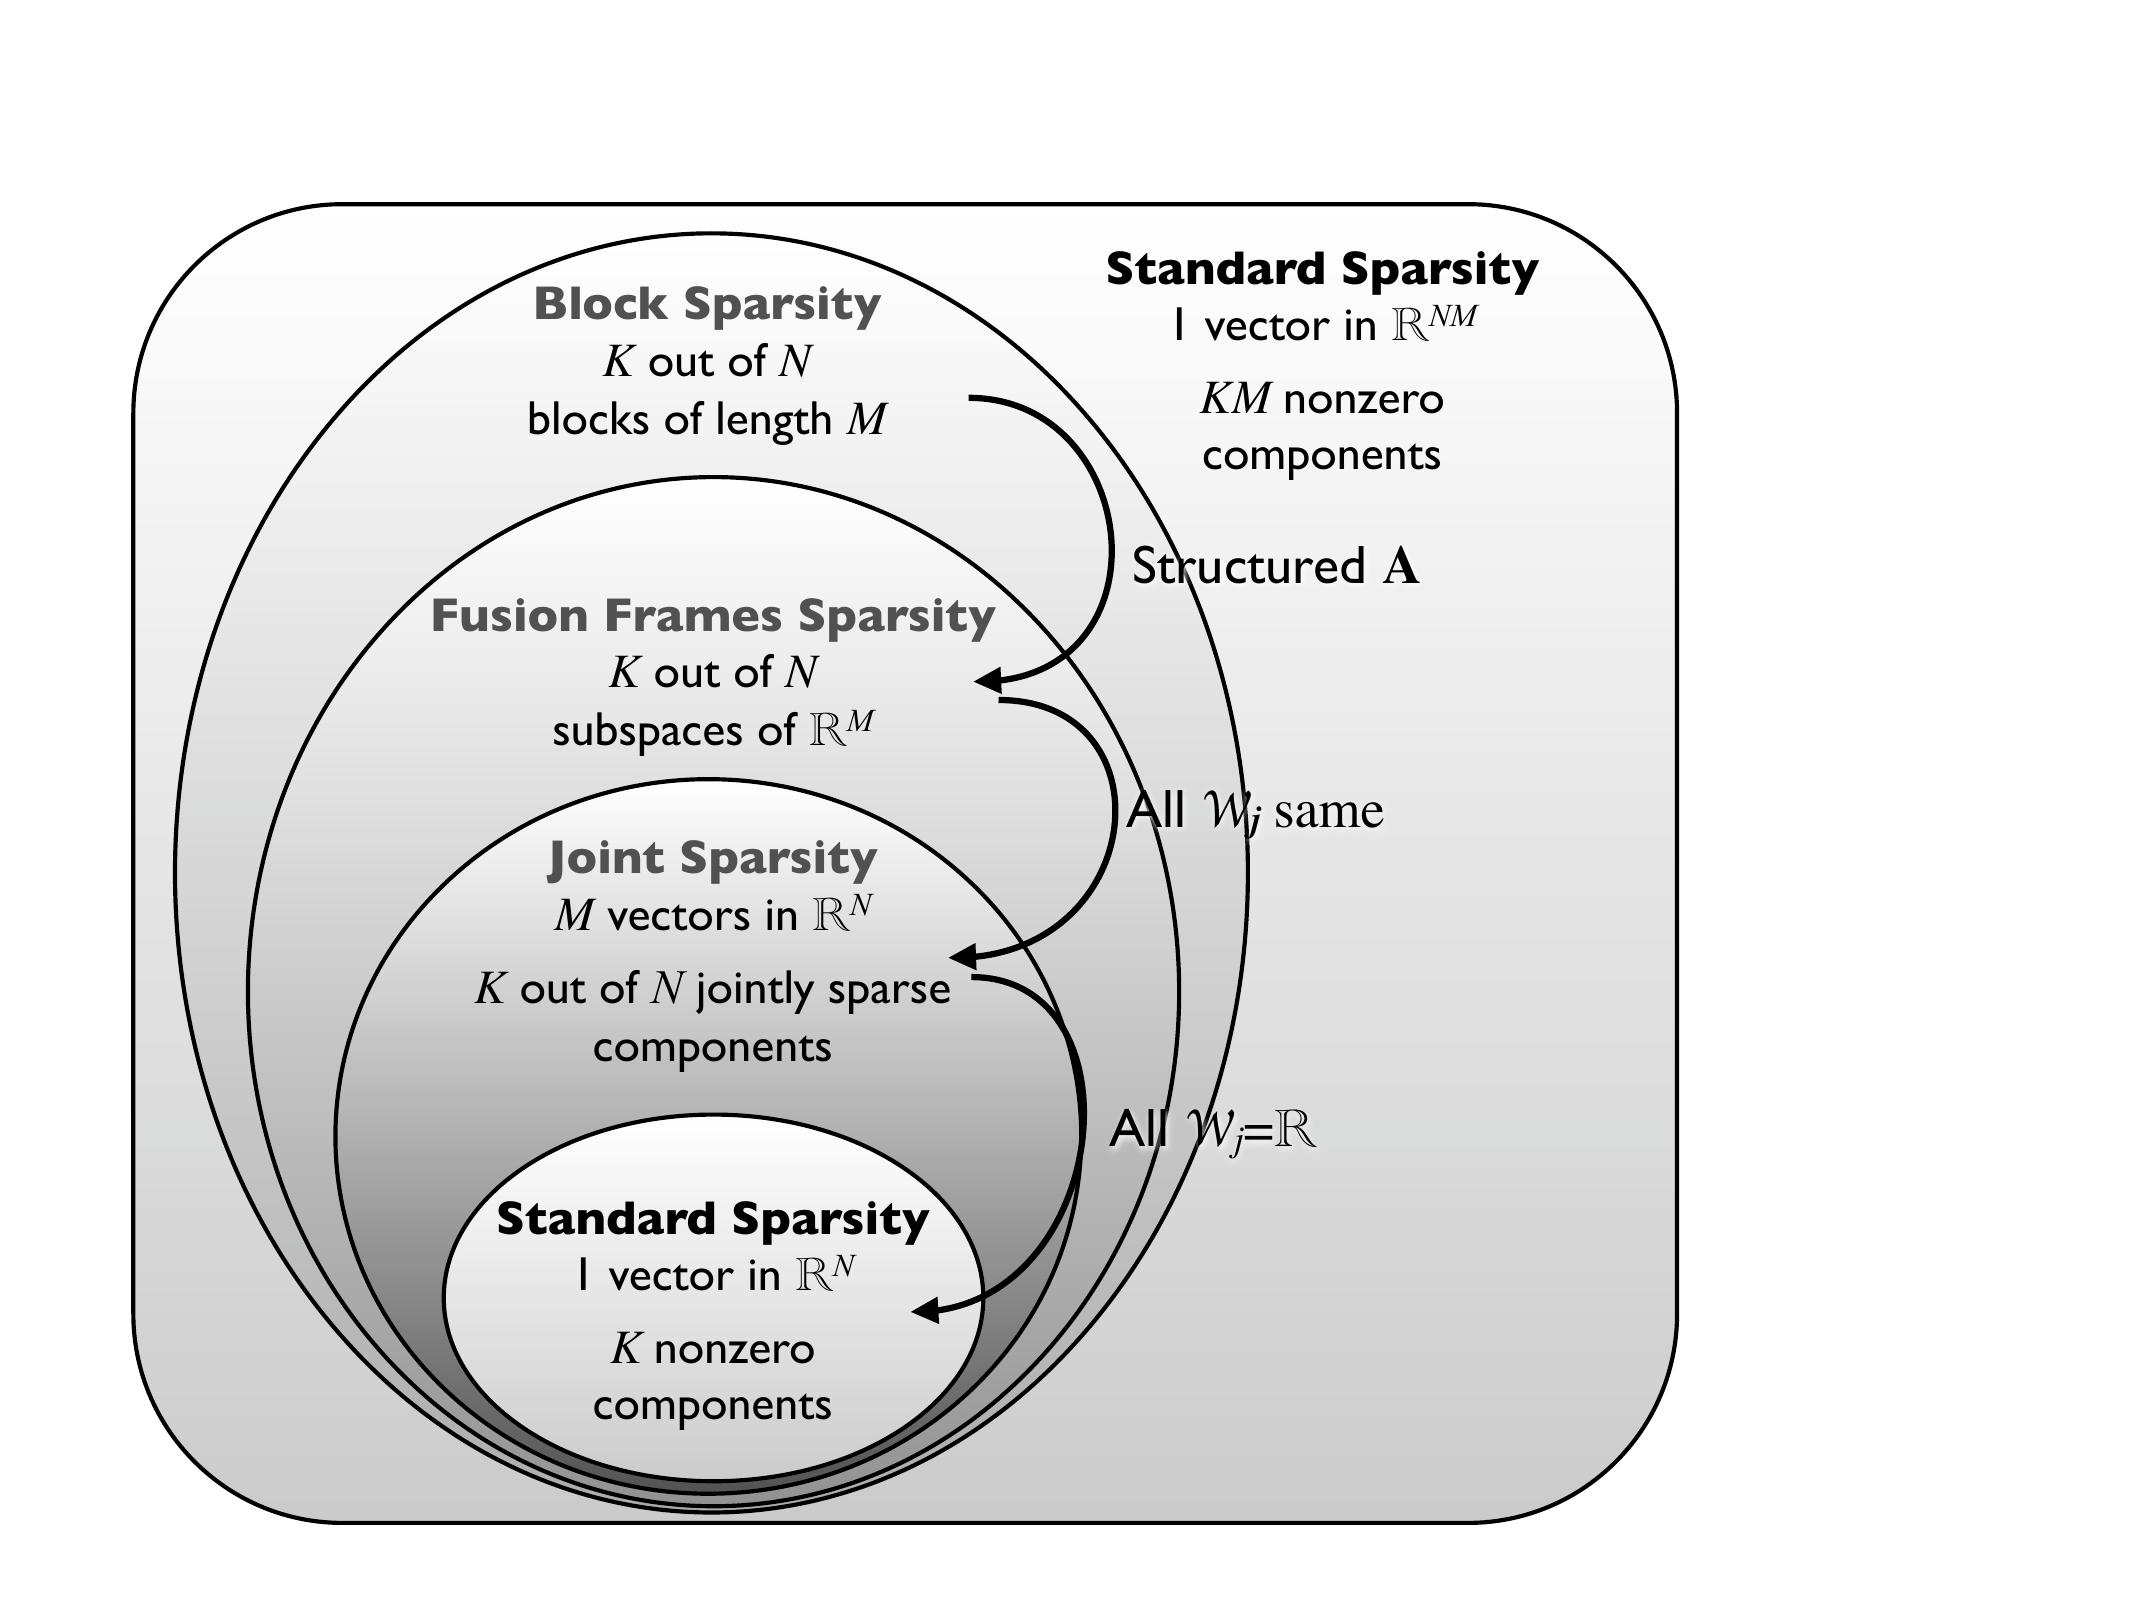 Figure 1
Peer Reviews
No public reviews on file for this paper yet. If you reviewed it on a platform where reviews are public (OpenReview, ICLR, NeurIPS, ICML), you can paste yours below so the community can read it here.
Videos
No videos yet. Explain this paper in a talk, walkthrough, or lecture? Add one.
Sparse Recovery from Combined Fusion Frame Measurements
Petros Boufounos, Gitta Kutyniok, and Holger Rauhut Manuscript received December 10, 2009; revised November 16, 2010; accepted December 14, 2010. Date of current version May 25, 2011. P. Boufounos did part of this work while at Rice university. P. Boufounos was supported in part by the grants NSF CCF-0431150, CCF-0728867, CNS-0435425, and CNS-0520280, DARPA/ONR N66001-08-1-2065, ONR N00014-07-1-0936, N00014-08-1-1067, N00014-08-1-1112, and N00014-08-1-1066, AFOSR FA9550-07-1-0301, ARO MURI W311NF-07-1-0185, and the Texas Instruments Leadership University Program. P. Boufounos was supported in part by Mitsubishi Electric Research Laboratories (MERL). G. Kutyniok was in part supported by Deutsche Forschungsgemeinschaft (DFG) Heisenberg Fellowship KU 1446/8, DFG Grant SPP-1324, KU 1446/13, and DFG Grant KU 1446/14. H. Rauhut acknowledges support by the Hausdorff Center for Mathematics and by the WWTF project SPORTS (MA 07-004). P. Boufounos is with Mitsubishi Electric Research Laboratories, [email protected].G. Kutyniok is with Institute of Mathematics, University of Osnabrück, [email protected].H. Rauhut is with Hausdorff Center for Mathematics & Institute for Numerical Simulation, University of Bonn, [email protected].Communicated by J. Romberg, Associate Editor for Signal Processing.Digital Object Identifier 10.1109/TIT.2011.2143890
Abstract
Sparse representations have emerged as a powerful tool in signal and information processing, culminated by the success of new acquisition and processing techniques such as Compressed Sensing (CS). Fusion frames are very rich new signal representation methods that use collections of subspaces instead of vectors to represent signals. This work combines these exciting fields to introduce a new sparsity model for fusion frames. Signals that are sparse under the new model can be compressively sampled and uniquely reconstructed in ways similar to sparse signals using standard CS. The combination provides a promising new set of mathematical tools and signal models useful in a variety of applications. With the new model, a sparse signal has energy in very few of the subspaces of the fusion frame, although it does not need to be sparse within each of the subspaces it occupies. This sparsity model is captured using a mixed norm for fusion frames.
A signal sparse in a fusion frame can be sampled using very few random projections and exactly reconstructed using a convex optimization that minimizes this mixed norm. The provided sampling conditions generalize coherence and RIP conditions used in standard CS theory. It is demonstrated that they are sufficient to guarantee sparse recovery of any signal sparse in our model. Moreover, a probabilistic analysis is provided using a stochastic model on the sparse signal that shows that under very mild conditions the probability of recovery failure decays exponentially with increasing dimension of the subspaces.
Index Terms:
Compressed sensing, minimization, -minimization, sparse recovery, mutual coherence, fusion frames, random matrices.
I Introduction
Compressed Sensing (CS) has recently emerged as a very powerful field in signal processing, enabling the acquisition of signals at rates much lower than previously thought possible [1, 2]. To achieve such performance, CS exploits the structure inherent in many naturally occurring and man-made signals. Specifically, CS uses classical signal representations and imposes a sparsity model on the signal of interest. The sparsity model, combined with randomized linear acquisition, guarantees that non-linear reconstruction can be used to efficiently and accurately recover the signal.
Fusion frames are recently emerged mathematical structures that can better capture the richness of natural and man-made signals compared to classically used representations [3]. In particular, fusion frames generalize frame theory by using subspaces in the place of vectors as signal building blocks. Thus signals can be represented as linear combinations of components that lie in particular, and often overlapping, signal subspaces. Such a representation provides significant flexibility in representing signals of interest compared to classical frame representations.
In this paper we extend the concepts and methods of Compressed Sensing to fusion frames. In doing so we demonstrate that it is possible to recover signals from underdetermined measurements if the signals lie only in very few subspaces of the fusion frame. Our generalized model does not require that the signals are sparse within each subspace. The rich structure of the fusion frame framework allows us to characterize more complicated signal models than the standard sparse or compressible signals used in compressed sensing techniques. This paper complements and extends our work in [4].
Introducing sparsity in the rich fusion frame model and introducing fusion frame models to the Compressed Sensing literature is a major contribution of this paper. We extend the results of the standard worst-case analysis frameworks in Compressed Sensing, using the sampling matrix null space property (NSP), coherence, and restricted isometry property (RIP). In doing so, we extend the definitions to fusion NSP, fusion coherence and fusion RIP to take into account the differences of the fusion frame model. The three approaches provide complementary intuition on the differences between standard sparsity and block-sparsity models and sparsity in fusion frame models. We note that in the special case that the subspaces in our model all have the same dimension, most of our results follow from previous analysis of block-sparsity models [5, 6]. But in the general case of different dimensions they are new.
Our understanding of the problem is further enhanced by the probabilistic analysis. As we move from standard sparsity to fusion frame or other vector-based sparsity models, worst case analysis becomes increasingly pessimistic. The probabilistic analysis provides a framework to discern which assumptions of the worst case model become irrelevant and which are critical. It further demonstrates the significance of the angles between the subspaces comprising the fusion frame. Although our analysis is inspired by the model and the analysis in [7], the tools used in that work do not extend to the fusion frame model. The analysis presented in Sec. V is the second major contribution of our paper.
In the remainder of this section we provide the motivation behind our work and describe some possible applications. Section II provides some background on Compressed Sensing and on fusion frames to serve as a quick reference for the fundamental concepts and our basic notation. In Section III we formulate the problem, establish the additional notation and definitions necessary in our development, and state the main results of our paper. We further explore the connections with existing research in the field, as well as possible extensions. In Section IV we prove deterministic recovery guarantees using the properties of the sampling matrix. Section V presents the probabilistic analysis of our model, which is more appropriate for typical usage scenarios. We conclude with a discussion of our results.
I-A Motivation
As technology progresses, signals and computational sensing equipment becomes increasingly multidimensional. Sensors are being replaced by sensor arrays and samples are being replaced by multidimensional measurements. Yet, modern signal acquisition theory has not fully embraced the new computational sensing paradigm. Multidimensional measurements are often treated as collections of one-dimensional ones due to the mathematical simplicity of such treatment. This approach ignores the potential information and structure embedded in multidimensional signal and measurement models.
Our ultimate motivation is to provide a better understanding of more general mathematical objects, such as vector-valued data points [8]. Generalizing the notion of sparsity is part of such understanding. Towards that goal, we demonstrate that the generalization we present in this paper encompasses joint sparsity models [9, 10] as a special case. Furthermore, it is itself a special case of block-sparsity models [11, 12, 5, 6], with significant additional structure.
I-B Applications
Although the development in this paper provides a general theoretical perspective, the principles and the methods we develop are widely applicable. In particular, the special case of joint (or simultaneous) sparsity has already been widely used in radar [13], sensor arrays [14], and MRI pulse design [15]. In these applications a mixed norm was used heuristically as a sparsity proxy. Part of our goals in this paper is to provide a solid theoretical understanding of such methods.
In addition, the richness of fusion frames allows the application of this work to other cases, such as target recognition and music segmentation. The goal in such applications is to identify, measure, and track targets that are not well described by a single vector but by a whole subspace. In music segmentation, for example, each note is not characterized by a single frequency, but by the subspace spanned by the fundamental frequency of the instrument and its harmonics [16]. Furthermore, depending on the type of instrument in use, certain harmonics might or might not be present in the subspace. Similarly, in vehicle tracking and identification, the subspace of a vehicle’s acoustic signature depends on the type of vehicle, its engine and its tires [17]. Note that in both applications, there might be some overlap in the subspaces which distinct instruments or vehicles occupy.
Fusion frames are quite suitable for such representations. The subspaces defined by each note and each instrument or each tracked vehicle generate a fusion frame for the whole space. Thus the fusion frame serves as a dictionary of targets to be acquired, tracked, and identified. The fusion frame structure further enables the use of sensor arrays to perform joint source identification and localization using far fewer measurements than a classical sampling framework. In Sec. III-E we provide a stylized example that demonstrates this potential.
We also envision fusion frames to play a key role in video acquisition, reconstruction and compression applications such as [18]. Nearby pixels in a video exhibit similar sparsity structure locally, but not globally. A joint sparsity model such as [9, 10] is very constraining in such cases. On the other hand, subspace-based models for different parts of an image significantly improve the modeling ability compared to the standard compressed sensing model.
I-C Notation
Throughout this paper denotes the standard norm. The operator norm of a matrix from into is written as .
II Background
II-A Compressed Sensing
Compressed Sensing (CS) is a recently emerged field in signal processing that enables signal acquisition using very few measurements compared to the signal dimension, as long as the signal is sparse in some basis. It predicts that a signal with only non-zero coefficients can be recovered from only suitably chosen linear non-adaptive measurements, compactly represented by
[TABLE]
A necessary condition for exact signal recovery of all -sparse is that
[TABLE]
where the ‘norm,’ , counts the number of non-zero coefficients in . In this case, recovery is possible using the following combinatorial optimization,
[TABLE]
Unfortunately this is an NP-hard problem [19] in general, hence is infeasible.
Exact signal recovery using computationally tractable methods can be guaranteed if the measurement matrix satisfies the null space property (NSP) [20, 21], i.e., if for all support sets of cardinality at most ,
[TABLE]
where denotes the vector which coincides with on the index set and is zero outside .
If the coherence of is sufficiently small, the measurement matrix satisfies the NSP and, therefore, exact recovery is guaranteed [22, 8]. The coherence of a matrix with unit norm columns , , is defined as
[TABLE]
Exact signal recovery is also guaranteed if obeys a restricted isometry property (RIP) of order [1], i.e., if there exists a constant such that for all -sparse signals
[TABLE]
We note the relation , which easily follows from Gershgorin’s theorem. If any of the above properties hold, then the following convex optimization program exactly recovers the signal from the measurement vector ,
[TABLE]
A surprising result is that random matrices with sufficient number of rows can achieve small coherence and small RIP constants with overwhelmingly high probability.
A large body of literature extends these results to measurements of signals in the presence of noise, to signals that are not exactly sparse but compressible [1], to several types of measurement matrices [23, 24, 25, 26, 27] and to measurement models beyond simple sparsity [28].
II-B Fusion Frames
Fusion frames are generalizations of frames that provide a richer description of signal spaces. A fusion frame for is a collection of subspaces and associated weights , compactly denoted by , that satisfies
[TABLE]
for some universal fusion frame bounds and for all , where denotes the orthogonal projection onto the subspace . We use to denote the dimension of the th subspace , . A frame is a special case of a fusion frame in which all the subspaces are one-dimensional (i.e., ), and the weights are the norms of the frame vectors. For finite and , the definition reduces to the requirement that the subspace sum of is equal to .
The generalization to fusion frames allows us to capture interactions between frame vectors to form specific subspaces that are not possible in classical frame theory. Similar to classical frame theory, we call the fusion frame tight if the frame bounds are equal, . If the fusion frame has , we call it a unit-norm fusion frame. In this paper, we will in fact restrict to the situation of unit-norm fusion frames, since the anticipated applications are only concerned with membership in the subspaces and do not necessitate a particular weighting.
Dependent on a fusion frame we define the Hilbert space as
[TABLE]
We should point out that depending on the use, can be represented as a very long vector or as a matrix. However, both representations are just rearrangements of vectors in the same Hilbert space, and we use them interchangeably in the manuscript.
Finally, let be a known but otherwise arbitrary matrix, the columns of which form an orthonormal basis for , , that is , where is the identity matrix, and .
The fusion frame mixed norm is defined as
[TABLE]
where are the fusion frame weights. Furthermore, for a sequence , , we similarly define the mixed norm
[TABLE]
The –‘norm’ (which is actually not even a quasi-norm) is defined as
[TABLE]
independent of . For the remainder of the paper we use just for the purpose of notation and to distinguish from the vector ’norm’. We call a vector -sparse, if .
III Sparse Recovery of Fusion Frame Vectors
III-A Measurement Model
We now consider the following scenario. Let , and assume that we only observe linear combinations of those vectors, i.e., there exist some scalars satisfying for all such that we observe
[TABLE]
where denotes the Hilbert space
[TABLE]
We first notice that (3) can be rewritten as
[TABLE]
i.e., is the matrix consisting of the blocks .
III-B Reconstruction using Convex Optimization
We now wish to recover from the measurements . If we impose conditions on the sparsity of , it is suggestive to consider the following minimization problem,
[TABLE]
Using the matrix , we can rewrite this optimization problem as
[TABLE]
However, this problem is NP-hard [19] and, as proposed in numerous publications initiated by [29], we prefer to employ minimization techniques. This leads to the investigation of the following minimization problem,
[TABLE]
Since we minimize over all and certainly by definition, we can rewrite this minimization problem as
[TABLE]
where
[TABLE]
Problem bears difficulties to implement since minimization runs over . Still, it is easy to see that is equivalent to the optimization problem
[TABLE]
where then . This particular form ensures that the minimizer lies in the collection of subspaces while minimization is performed over for all and , hence feasible.
Finally, by rearranging (III-B), the optimization problems, invoking the -‘norm’ and -norm, can be rewritten using matrix-only notation as
[TABLE]
and
[TABLE]
in which
[TABLE]
Hereby, we additionally used that by orthonormality of the columns of . We follow this notation for the remainder of the paper.
III-C Worst Case Recovery Conditions
To guarantee that always recovers the original signal , we provide three alternative conditions, in line with the standard CS literature [8, 23, 1, 20, 30, 31, 32, 22]. Specifically, we define the fusion null space property, the fusion coherence, and the fusion restricted isometry propery (FRIP). These are fusion frame versions of the null space property, the coherence and the RIP, respectively.
Definition III.1
The pair , with a matrix and a fusion frame is said to satisfy the fusion null space property if
[TABLE]
for all support sets of cardinality at most . Here denotes the null space , and denotes the vector which coincides with on the index set and is zero outside .
Definition III.2
The fusion coherence of a matrix with normalized ‘columns’ and a fusion frame for is given by
[TABLE]
where denotes the orthogonal projection onto , .
Definition III.3
Let and be a fusion frame for and as defined in (4). The fusion restricted isometry constant is the smallest constant such that
[TABLE]
for all , , of sparsity .
In the case that the subspaces have the same dimension the definitions of fusion coherence and fusion RIP coincide with those of block coherence and block RIP introduced in [5, 6]. This is expected, as we discuss in Sec. III-E, since the fusion sparsity model is a special case of general block sparsity models.
Using those definitions, we provide three alternative recovery conditions, also in line with standard CS results. We first state the characterization via the fusion null space property.
Theorem III.4
Let and be a fusion frame. Then all , , with are the unique solution to with if and only if satisfies the fusion null space property of order .
While the fusion null space property characterizes recovery, it is somewhat difficult to check in practice. The fusion coherence is much more accessible for a direct calculation, and the next result states a corresponding sufficient condition. In the case, that the subspaces have the same dimension the theorem below reduces to Theorem 3 in [6] on block-sparse recovery.
Theorem III.5
Let with normalized columns , let be a fusion frame in , and let . If there exists a solution of the system satisfying
[TABLE]
then this solution is the unique solution of as well as of .
Finally, we state a sufficient condition based on the fusion RIP, which allows stronger recovery results, but is more difficult to evaluate than the fusion coherence. The constant below is not optimal and can certainly be improved, but our aim was rather to have a short proof. Furthermore, in the case that all the subspaces have the same dimension, the fusion frame setup is equivalent to the block-sparse case, for which the next theorem is implied by Theorem 1 in [5].
Theorem III.6
Let with fusion frame restricted isometry constant . Then recovers all -sparse from .
III-D Probability of Correct Recovery
Intuitively, it seems that the higher the dimension of the subspaces , the ‘easier’ the recovery via the minimization problem [7] should be. However, it turns out that this intuition only holds true if we consider a probabilistic analysis. Thus we provide a probabilistic signal model and a typical case analysis for the special case where all the subspaces have the same dimension for all . Inspired by the probability model in [7], we will assume that on the -element support set the entries of the vectors , , are independent and follow a normal distribution,
[TABLE]
where is a Gaussian random vector, i.e., all entries are independent standard normal random variables.
Our probabilistic result shows that the failure probability for recovering decays exponentially fast with growing dimension of the subspaces. Interestingly, the quantity involved in the estimate is again dependent on the ‘angles’ between subspaces and is of the flavor of the fusion coherence in Def. III.2. Since the block-sparsity model can be seen as a special case of the fusion frame sparsity model, the theorem clearly applies also to this scenario.
Theorem III.7
Let be a set of cardinality and suppose that satisfies
[TABLE]
Let be a fusion frame with associated orthogonal bases and orthogonal projections , and let . Further, let , with such that the coefficients on are given by (8), and let be defined by
[TABLE]
Choose . Then with probability at least
[TABLE]
the minimization problem recovers from . In particular, the failure probability can be estimated by
[TABLE]
Let us note that [7, Section V] provides several mild conditions that imply (9). We exemplify one of these. Suppose that the columns of form a unit norm tight frame with (ordinary) coherence . (This condition is satisfied for a number of explicitly given matrices, see also [7].) Suppose further that the support set is chosen uniformly at random among all subsets of cardinality . Then with high probability (9) is satisfied provided , see Theorem 5.4 and Section V.A in [7]. This is in sharp contrast to deterministic recovery guarantees based on coherence, which cannot lead to better bounds than . Further note, that the quantity is bounded by in the worst case, but maybe significantly smaller if the subspaces are close to orthogonal. Clearly, can only be varied by changing the fusion frame model, and may also change in this case. While, in principle, may grow with , typically actually decreases; for instance if the subspaces are chosen at random. In any case, since always , the failure probability of recovery decays exponentially in the dimension of the subspaces.
III-E Relation with Previous Work
A special case of the problem above appears when all subspaces are equal and also equal to the ambient space for all . Thus, and the observation setup of Eq. (3) is identical to the matrix product
[TABLE]
This special case is the same as the well studied joint sparsity setup of [33, 9, 10, 34, 7] in which a collection of sparse vectors in is observed through the same measurement matrix , and the recovery assumes that all the vectors have the same sparsity structure. The use of mixed optimization has been proposed and widely used in this case.
The following simple example illustrates how a fusion frame model can reduce the sampling required compared to simple joint sparsity models. Consider the measurement scenario of (10), rewritten in an expanded form:
[TABLE]
where and . Using the fusion frames notation, is a fusion frame representation of our acquired signal, which we assume sparse as we defined in Sec. II-B. For the purposes of the example, suppose that only and have significant content and the remaining components are zero. Thus we only focus on the measurement vectors and and their relationship, with respect to the subspaces and where and lie in.
Using the usual joint sparsity models, would require that and have low coherence (1), even if prior information about and provided a better signal model. For example, if we know from the problem formulation that the two components and lie in orthogonal subspaces , we can select and to be identical, and still be able to recover the signal. If, instead, and only have a common overlapping subspace we need and to be incoherent only when projected on that subspace, as measured by fusion coherence, defined in Def. III.2, and irrespective of the dimensionality of the two subspaces and the dimensionality of their common subspace. This is a case not considered in the existing literature.
The practical applications are significant. For example, consider a wideband array signal acquisition system in which each of the signal subspaces are particular targets of interest from particular directions of interest (e.g. as an extremely simplified stylized example consider as the subspace of friendly targets and as the subspace of enemy targets from the same direction). If two kinds of targets occupy two different subspaces in the signal space, we can exploit this in the acquisition system. This opens the road to subspace-based detection and subspace-based target classification dictionaries.
Our formulation is a special case of the block sparsity problem [11, 12, 6], where we impose a particular structure on the measurement matrix . This relationship is already known for the joint sparsity model, which is also a special case of block sparsity. In other words, the fusion frame formulation we examine here specializes block sparsity problems and generalizes joint sparsity ones.
For the special case of fusion frames in which all the subspaces have the same dimension, our definition of coherence can be shown to be essentially the same (within a constant scaling factor) as the one in [6] when the problem is reformulated as a block sparsity one. Similarly, for the same special case our definition of the NSP becomes similar to the one in [35].
We would also like to note that the hierarchy of such sparsity problems depends on their dimension. For example, a joint sparsity problem with becomes the standard sparsity model. In that sense, joint sparsity models generalize standard sparsity models. The hierarchy of sparsity models is illustrated in the Venn diagram of Fig. 1.
III-F Extensions
Several extensions of this formulation and the work in this paper are possible, but beyond our scope. For example, the analysis we provide is in the exactly sparse, noiseless case. As with classical compressed sensing, it is possible to accommodate sampling in the presence of noise. It is also natural to consider the extension of this work to sampling signals that are not -sparse in a fusion frame representation but can be very well approximated by such a representation. (However, see Section IV-D.)
The richness of fusion frames also allows us to consider richer sampling matrices. Specifically, it is possible to consider sampling operators consisting of different matrices, each operating on a separate subspace of the fusion frame. Such extensions open the use of methods to general vector-valued mathematical objects, to the general problem of sampling such objects [8], and to general model-based CS problems [28].
IV Deterministic Recovery Conditions
In this section we derive conditions on and so that is the unique so lution of () as well as of (). Our approach uses the generalized notions of null space property, coherence and the restricted isometry property, all commonly used measures of morphological difference between the vectors of a measuring matrix.
IV-A Fusion Null Space Property
We first prove Thm. III.4, which demonstrates that the fusion NSP guarantees recovery, similarly to the standard CS setup [20]. This notion will also be useful later to prove recovery bounds using the fusion coherence and using the fusion restricted isometry constants.
Proof:
Assume first that the fusion NSP holds. Let be a vector with , and let be an arbitrary solution of the system , and set
[TABLE]
Letting denote the support of , we obtain
[TABLE]
This term is greater than zero for any provided that
[TABLE]
or, in other words,
[TABLE]
which is ensured by the fusion NSP.
Conversely, assume that all vectors with are recovered using . Then, for any and any with , the -sparse vector is the unique minimizer of subject to . Further, observe that and , since . Therefore, , which is equivalent to the fusion NSP because was arbitrary. ∎
IV-B Fusion Coherence
The fusion coherence is an adaptation of the coherence notion to our more complicated situation involving the angles between the subspaces generated by the bases , . In other words, here we face the problem of recovery of vector-valued (instead of scalar-valued) components and our definition is adapted to handle this.
Since the ’s are projection matrices, we can also rewrite the definition of fusion coherence as
[TABLE]
with denoting the largest eigenvalue, simply due to the fact that the eigenvalues of and coincide. Indeed, if is an eigenvalue of with corresponding eigenvector then . Since this implies that so that is an eigenvalue of with eigenvector . Let us also remark that equals the largest absolute value of the cosines of the principle angles between and .
Before we continue with the proof of the recovery condition in Theorem III.5, let us for a moment consider the following special cases of this theorem.
Case
In this case the projection matrices equal , and hence the problem reduces to the classical recovery problem with and . Thus our result reduces to the result obtained in [36], and the fusion coherence coincides with the commonly used mutual coherence, i.e., .
Case for all
In this case the problem becomes the standard joint sparsity recovery. We recover a matrix with few non-zero rows from knowledge of , without any constraints on the structure of each row of . The recovered matrix is the fusion frame representation of the sparse vector and each row represents a signal in the subspace (the general case has the constraint that is required to be of the form ). Again fusion coherence coincides with the commonly used mutual coherence, i.e., .
Case for all
In this case the fusion coherence becomes 0. And this is also the correct answer, since in this case there exists precisely one solution of the system for a given . Hence Condition (7) becomes meaningless.
General Case
In the general case we can consider two scenarios: either we are given the subspaces or we are given the measuring matrix . In the first situation we face the task of choosing the measuring matrix such that is as small as possible. Intuitively, we would choose the vectors so that a pair has a large angle if the associated two subspaces have a small angle, hence balancing the two factors and try to reduce the maximum. In the second situation, we can use a similar strategy now designing the subspaces accordingly.
For the proof of Theorem III.5 we first derive a reformulation of the equation . For this, let denote the orthogonal projection onto for each , set as in (4) and define the map , by
[TABLE]
i.e., the concatenation of the rows. Then it is easy to see that
[TABLE]
We now split the proof of Theorem III.5 into two lemmas, and wish to remark that many parts are closely inspired by the techniques employed in [36, 31]. We first show that satisfying (7) is the unique solution of .
Lemma IV.1
If there exists a solution of the system with satisfying (7), then is the unique solution of .
Proof:
We aim at showing that the condition on the fusion coherence implies the fusion NSP. To this end, let , i.e., . By using the reformulation (14), it follows that
[TABLE]
This implies that
[TABLE]
Defining by for each , the previous equality can be computed to be
[TABLE]
Recall that we have required the vectors to be normalized. Hence, for each ,
[TABLE]
Since for any , this gives
[TABLE]
which implies
[TABLE]
Thus, we have
[TABLE]
Concluding, (7) and the fusion null space property show that satisfies (13) unless , which implies that is the unique minimizer of as claimed. ∎
Using Lemma IV.1 it is easy to show the following lemma.
Lemma IV.2
If there exists a solution of the system with satisfying (7), then is the unique solution of .
Proof:
Assume satisfies (7) and . Then, by Lemma IV.1, it is the unique solution of . Assume there is a satisfying such that . Then also satisfies (7) and again by Lemma IV.1 is also the unique solution to . But this means that and is the unique solution to . ∎
We observe that Theorem III.5 now follows immediately from Lemmas IV.1 and IV.2.
IV-C Fusion Restricted Isometry Property
Finally, we consider the condition for sparse recovery using the restricted isometry property (RIP) of the sampling matrix. The RIP property on the sampling matrix, first introduced in [1], complements the null space propery and the mutual coherence conditions. Definition III.3 generalizes it for the fusion frame setup. Informally, we say that satisfies the fusion restricted isometry property (FRIP) if is small for reasonably large . Note that we obtain the classical definition of the RIP of if and all the subspaces have dimension . Using this property we can prove Theorem III.6.
Proof:
The proof proceeds analogously to the one of Theorem 2.6 in [26], that is, we establish the fusion NSP. The claim will then follow from Theorem III.4.
Let us first note that
[TABLE]
for all , , with and . This statement follows completely analogously to the proof of Proposition 2.5(c) in [32], see also [37, 20].
Now let be given. Using the reformulation (14), it follows that
[TABLE]
In order to show the fusion NSP it is enough to consider an index set of size of largest components , i.e., for all , . We partition into index sets of size (except possibly the last one), such that is an index set of largest components in , is an index set of largest components in , etc. Let be the vector that coincides with on and is set to zero outside. In view of we have . Now set and . It follows that . By definition of the FRIP we obtain
[TABLE]
Using that and dividing by yields
[TABLE]
By construction of the sets we have for all , hence,
[TABLE]
The Cauchy-Schwarz inequality yields
[TABLE]
where we used the assumption . Hence, the fusion null space property follows. ∎
Having proved that the FRIP ensures signal recovery, our next proposition relates the classical RIP with our newly introduced FRIP. Let us note, however, that using the RIP to guarantee the FRIP does not take into account any properties of the fusion frame, so it is sub-optimal—especially if the subspaces of the fusion frame are orthogonal or almost orthogonal.
Proposition IV.3
Let with classical restricted isometry constant , that is,
[TABLE]
for all -sparse . Let be an arbitrary fusion frame for . Then the fusion restricted isometry constant of satisfies .
Proof:
Let satisfy , and denote the columns of the matrix by . The condition implies that each is -sparse. Since satisfies the RIP of order with constant , we obtain
[TABLE]
as well as
[TABLE]
This proves the proposition because . ∎
IV-D Additional Remarks and Extensions
Of course, it is possible to extend the proof of Theorem III.6 in a similar manner to [1, 37, 38, 39] such that we can accommodate measurement noise and signals that are well approximated by sparse fusion frame representation. We state the analog of the main theorem of [37] without proof.
Theorem IV.4
Assume that the fusion restricted isometry constant of satisfies
[TABLE]
For , let noisy measurements be given with . Let be the solution of the convex optimization problem
[TABLE]
and set . Then
[TABLE]
where is obtained from be setting to zero all components except the largest in norm. The constants only depend on (or rather on ).
V Probabilistic Analysis
V-A General Recovery Condition
We start our analysis by deriving a recovery condition on the measurement matrix and the signal which the reader might want to compare with [40, 41]. Given a matrix , we let denote the matrix which is generated from by normalizing each entry by the norm of the corresponding row . More precisely,
[TABLE]
Column vectors are defined similarly by .
Under a certain condition on , which is dependent on the support of the solution, we derive the result below on unique recovery. To phrase it, let be a fusion frame with associated orthogonal bases and orthogonal projections , and recall the definition of the notion in Section III. Then, for some support set of , we let
[TABLE]
and
[TABLE]
Before stating the theorem, we wish to remark that its proof uses similar ideas as the analog proof in [7]. We however state all details for the convenience of the reader.
Theorem V.1
Retaining the notions from the beginning of this section, we let , with . If is non-singular and there exists a matrix such that
[TABLE]
and
[TABLE]
then is the unique solution of .
Proof:
Let , be a solution of , set , and suppose is non-singular and the hypotheses (15) and (16) are satisfied for some matrix . Let , with for some be a different set of coefficient vectors which satisfies . To prove our result we aim to establish that
[TABLE]
We first observe that
[TABLE]
Set , apply (15), and exploit properties of the trace,
[TABLE]
Now use the Cauchy-Schwarz inequality to obtain
[TABLE]
The strict inequality follows from , which is true because otherwise would be supported on . The equality would then be in contradiction to the injectivity of (recall that ). This concludes the proof. ∎
The matrix exploited in Theorem V.1 might be chosen as
[TABLE]
to satisfy (15). This particular choice will in fact be instrumental for the average case result we are aiming for. For now, we obtain the following result as a corollary from Theorem V.1.
Corollary V.2
Retaining the notions from the beginning of this section, we let , , with . If is non-singular and
[TABLE]
then is the unique solution of .
For later use, we will introduce the matrices defined by
[TABLE]
where is the th block. For some , we can then write as
[TABLE]
Using the above and the probabilistic model in Sec. III-D to prove our main probabilistic result, Theorem III.7.
V-B Probability of Sparse Recovery for Fusion Frames
The proof of our probabilistic result, Theorem III.7, is developed in several steps. A key ingredient is a concentration of measure result: If is a Lipschitz function on with Lipschitz constant , i.e., for all , is a -dimensional vector of independent standard normal random variables then [42, eq. (2.35)]
[TABLE]
Our first lemma investigates the properties of a function related to (19) that are needed to apply the above inequality.
Lemma V.3
Let and . Define the function by
[TABLE]
Then the following holds.
- (i)
* is Lipschitz with constant .*
- (ii)
For a standard Gaussian vector we have .
Proof:
The claim in (i) follows immediately from
[TABLE]
It remains to prove (ii). Obviously,
[TABLE]
Invoking the conditions on ,
[TABLE]
∎
Next we estimate the Lipschitz constant of the function in the previous lemma.
Lemma V.4
Let and . Then
[TABLE]
Proof:
First observe that
[TABLE]
Since
[TABLE]
it follows that
[TABLE]
Next,
[TABLE]
By definition of the orthogonal projections ,
[TABLE]
Combining with (V-B),
[TABLE]
The lemma now follows from (21), (V-B), and (23). ∎
Now we have collected all ingredients to prove our main result, Theorem III.7
Proof:
Denote for all and choose . By Corollary V.2, the probability that the minimization problem () fails to recover from can be estimated as
[TABLE]
Since is a standard Gaussian vector in [43, Corollary 3] gives
[TABLE]
Furthermore, the concentration inequality (20) combined with Lemmas V.3 and Lemma V.4 yields
[TABLE]
Combining the above estimates yields the statement of the Theorem. ∎
VI Conclusions and Discussion
The main contribution in this paper is the generalization of standard Compressed Sensing results for sparse signals to signals that have a sparse fusion frame representation. As we demonstrated, the results generalize to fusion frames in a very nice and easy to apply way, using the mixed norm.
A key result in our work shows that the structure in fusion frames provides additional information that can be exploited in the measurement process. Specifically, our definition of fusion coherence demonstrates the importance of prior knowledge about the signal structure. Indeed, if we know that the signal lies in subspaces with very little overlap (i.e., where is small in Definition III.2) we can relax the requirement on the coherence of the corresponding vectors in the sampling matrix (i.e., in the same definition) and maintain a low fusion coherence. This behavior emerges from the inherent structure of fusion frames.
The emergence of this behavior is evident both in the guarantees provided by the fusion coherence, and in our average case analysis. Unfortunately, our analysis of this property currently has not been incorporated in a tight approach to satisfying the Fusion RIP property, as described in Section IV-C. While an extension of such analysis for the RIP guarantees is desirable, it is still an open problem.
Our average case analysis also demonstrates that as the sparsity structure of the problem becomes more intricate, the worst case analysis can become too pessimistic for many practical cases. The average case analysis provides reassurance that typical behavior is as expected; significantly better compared to the worst case. Our results corroborate and extend similar findings for the special case of joint sparsity in [7].
Acknowledgement
G. Kutyniok would like to thank Peter Casazza, David Donoho, and Ali Pezeshki for inspiring discussions on minimization and fusion frames. G. Kutyniok would also like to thank the Department of Statistics at Stanford University and the Department of Mathematics at Yale University for their hospitality and support during her visits.
The reference list from the paper itself. Each links out to its DOI / PubMed record.
- 1[1] E. J. Candès, J. K. Romberg, and T. Tao, “Stable signal recovery from incomplete and inaccurate measurements,” Comm. Pure Appl. Math. , vol. 59, no. 8, pp. 1207–1223, 2006.
- 2[2] D. L. Donoho, “Compressed sensing,” IEEE Trans. Inform. Theory , vol. 52, no. 4, pp. 1289–1306, 2006.
- 3[3] P. G. Casazza, G. Kutyniok, and S. Li, “Fusion Frames and Distributed Processing,” Appl. Comput. Harmon. Anal. , vol. 25, pp. 114–132, 2008.
- 4[4] P. Boufounos, G. Kutyniok, and H. Rauhut, “Compressed sensing for fusion frames,” in Proc. SPIE, Wavelets XIII , vol. 7446, 2009, doi:10.1117/12.826327.
- 5[5] Y. Eldar and M. Mishali, “Robust recovery of signals from a structured union of subspaces,” IEEE Trans. Inform. Theory , vol. 55, no. 11, pp. 5302–5316, 2009.
- 6[6] Y. Eldar, P. Kuppinger, and H. Bolcskei, “Block-sparse signals: Uncertainty relations and efficient recovery,” Signal Processing, IEEE Transactions on , vol. 58, no. 6, pp. 3042 –3054, 2010.
- 7[7] Y. Eldar and H. Rauhut, “Average case analysis of multichannel sparse recovery using convex relaxation,” IEEE Trans. Inform. Theory , vol. 56, no. 1, pp. 505–519, 2010.
- 8[8] A. M. Bruckstein, D. L. Donoho, and M. Elad, “From Sparse Solutions of Systems of Equations to Sparse Modeling of Signals and Images,” SIAM Review , vol. 51, no. 1, pp. 34–81, 2009.