Topology of spaces of equivariant symplectic embeddings
Alvaro Pelayo

TL;DR
This paper determines the homotopy type of the space of equivariant symplectic embeddings into symplectic-toric manifolds and introduces an invariant based on this topology.
Contribution
It computes the homotopy type of equivariant embedding spaces and defines a new invariant for symplectic-toric manifolds.
Findings
Homotopy type of equivariant embedding space computed
A Z-valued step function invariant is introduced
Results extend to partially equivariant cases
Abstract
We compute the homotopy type of the space of T^n-equivariant symplectic embeddings from the standard 2n-dimensional ball of some fixed radius into a 2n-dimensional symplectic-toric manifold M, and use this computation to define a Z-valued step function on the positive real line which is an invariant of the symplectic-toric type of M. We conclude with a discussion of the partially equivariant case of this result.
Click any figure to enlarge with its caption.
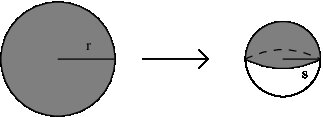 Figure 1
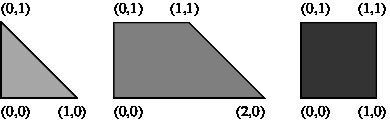 Figure 2
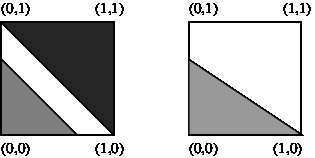 Figure 3
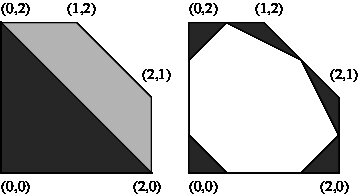 Figure 4
Peer Reviews
No public reviews on file for this paper yet. If you reviewed it on a platform where reviews are public (OpenReview, ICLR, NeurIPS, ICML), you can paste yours below so the community can read it here.
Videos
No videos yet. Explain this paper in a talk, walkthrough, or lecture? Add one.
Taxonomy
TopicsGeometric and Algebraic Topology · Homotopy and Cohomology in Algebraic Topology · Advanced Algebra and Geometry
Topology of spaces of equivariant symplectic embeddings
Alvaro Pelayo
Abstract
We compute the homotopy type of the space of -equivariant symplectic embeddings from the standard -dimensional ball of some fixed radius into a -dimensional symplectic–toric manifold , and use this computation to define a -valued step function on which is an invariant of the symplectic–toric type of . We conclude with a discussion of the partially equivariant case of this result.
1 The main theorem
Let be a -dimensional symplectic manifold and write for the compact -ball of radius in the complex space equipped with the restriction of the standard symplectic form of . (The proofs of the results in this paper hold verbatim for the open ball.) Recently a lot of effort has been put into understanding the topological and geometric properties of the space of symplectic embeddings from into . This question is not only intriguing, but it is also very fundamental because it acknowledges one of the main differences that exist between Riemannian and symplectic geometry, e.g. Gromov’s non–squeezing theorem [12].
This question, posed with such generality, has proven to be extremely difficult to answer. Significant progress has been made by McDuff [17], [18], Biran [3], [5] and most recently by Lalonde–Pinsonnault [14], among other authors. One of the most general results is due to McDuff; she showed the connectedness of the space of 4-balls into 4-manifolds with non-simple Seiberg–Witten type, in particular rational or ruled surfaces. Recall that we say that a symplectic -manifold has simple Seiberg–Witten type or just simple type if the only non–zero Gromov invariants of occur in classes for which . It follows from work of Taubes and Li–Liu that the symplectic -manifolds with non–simple type are blow–ups of (i) rational and ruled manifolds; (ii) manifolds with , , like the Enriques or Barlow surface; and (iii) manifolds with and ; examples (with ) are hyperelliptic surfaces, some non–Kähler -bundles over and quotients where is a surface of genus greater than , and is certain finite group. See [17] for further references and examples.
McDuff’s techniques are unique to dimension 4 and do not extend at all to higher dimensions—this is also the case in the other authors’ work—existence of -holomorphic curves with special homological properties is essential in their proofs. Although -holomorphic curves exist in all even dimensions, it is only in dimension where these homological properties hold.
In the present paper we study a special case of this question: is a symplectic–toric manifold of arbitrary dimension, and the symplectic embeddings that we consider preserve the toric structure, see Figure 1. Precisely this means that there exists an automorphism of the -torus such that the following diagram commutes:
[TABLE]
where is a fixed effective and Hamiltonian -action on and denotes the standard action by rotations on (component by component). In this case we say that is a -equivariant mapping.
The feature that makes the study of symplectic manifolds equipped with Hamiltonian torus actions richer than the study of generic symplectic manifolds is the presence of the smooth momentum map whose image is a convex polytope (called the momentum polytope of , cf. Figure 2) as shown independently by Atiyah and Guillemin–Sternberg [1], [8]. Here we are identifying the Lie algebra and its dual with . Since this identification is not canonical, we need to specify the convention we adopt in this paper. This amounts to choosing an epimorphism which we take to be . This epimorphism induces an isomorphism between and via , giving rise to a new isomorphism , , by canonically identifying with the product of copies of (see [9] for more details).
For example, under the convention of the previous paragraph, the momentum map of is a mapping from into with components , for all integer with . (There are a number of different conventions used in the literature, and our choice is intended to give the simplest formula for the momentum map of .) The simplest symplectic manifolds which admit Hamiltonian effective torus actions are called symplectic–toric.
**Definition 1.1 ** A symplectic–toric manifold , also called a Delzant manifold, is a compact connected symplectic manifold equipped with an effective Hamiltonian action of a torus of dimension half of the dimension of the manifold. In this case the momentum polytope is called the Delzant polytope of .
Symplectic–toric manifolds were classified by Delzant in [7]. In particular, he showed that the momentum image of such a manifold under the momentum map completely determines up to equivariant symplectomorphisms.
The main result of this paper, Theorem 1.2 below, describes the topology of the space of equivariant embeddings of symplectic balls into a symplectic–toric manifold. We denote by the Euler characteristic of .
Theorem 1.2**.**
For every symplectic–toric -manifold there is an associated -valued non–increasing step function such that for each the space of equivariant symplectic embeddings from the -ball into is homotopically equivalent to a disjoint union of subspaces, each of which is homeomorphic to the -torus .
As a matter of fact we can explicitly and easily read from the polytope :
**Example 1.3 ** Let equal the blow–up of with whose Delzant polytope has vertices at , , , and (see Figure 4). Then , where denotes the characteristic function of . We identify the -sphere of radius equipped with the standard area form with , where is the Fubini–Study form.
Proposition 1.4**.**
The function given in Theorem 1.2 is an invariant of the symplectic–toric type of and is given by the formula
[TABLE]
where for each fixed point , if the infimum of the -lengths of the edges of meeting at is strictly greater than , and otherwise.
**Example 1.5 ** Let be the Fubini–Study form on and observe that acts naturally on , , with fixed points. The momentum polytope is a tetrahedrum with vertices at and where the are the canonical basis vectors in . So if , the space of equivariant symplectic embeddings from into is homotopically equivalent to
[TABLE]
if , and it is empty otherwise.
The study of the space of symplectic embeddings is directly related to the study of the symplectic ball packing problem cf. [4], the equivariant version of which was treated in [19].
2 Proof of Theorem 1.2
In this section we prove Theorem 1.2. For clarity, the proof is divided in three steps, which we describe next.
We start by introducing the notation and making the following observations:
- i)
Throughout the proof will denote the space of rotations by matrices of the form with (the symmetric group) and , and will denote the space of equivariant symplectic embeddings from into such that and , equipped with the -Whitney topology (). Throughout the present section we fix .
Since each component of is canonically identified with the -torus (cf. Corollary 2.5), Theorem 1.2 amounts to prove that if ( denotes the -fixed point set) is such that , then the space gets identified with via a homotopy equivalence. 2. ii)
Secondly let denote the space of equivariant symplectomorphisms of (again with respect to the -Whitney topology).
Recall that, for example, the -Whitney topology on is given by the well–known norm
[TABLE]
where we are taking the norm on the right–hand side of this expression to be the canonical Euclidean norm on the space of matrices with complex entries. 3. iii)
We identify the automorphism group with the matrix group. 4. iv)
The elements ’s, , denote the weights of the isotropy representation of on ; the canonical basis vectors represent the weights of the isotropy representation of on .
Step 1: Invariance of the image .
In this step we first show how to go from smooth maps on manifolds to affine maps on polytopes (see diagram (2.7)), and secondly we use this to show the invariance of the image . Precisely, one can think of an embedding being equivariant in the sense of commuting with the -action, and it is when we reparametrize the torus that appears.
Lemma 2.1**.**
Let be any -equivariant and symplectic embedding such that the normalization condition holds. Then for all , if denotes the -orbit that passes through , the identity holds, and therefore .
Proof.
Let be -equivariant and symplectic embeddings from into with . Under the identifications described in Section 1, the following diagram commutes, where the top arrow stands for the affine map with linear part , which takes to :
[TABLE]
In order to prove the commutativity of diagram (2.7), we denote by the vector field induced by the element via the exponential map and note that from the definition of the momentum maps and , the -equivariance of , and the fact that , we have the following sequence of equalities, where and denote, respectively, the tangent mapping of at and of at ,
[TABLE]
where , and . Therefore by equation (2.8) and by using the chain rule we obtain that for all and
[TABLE]
Considering equation (2.9), and and composing with , after integration we obtain the commutativity condition on diagram (2.7). Notice that diagram (2.7) also holds for the embedding .
Then it follows from the conjunction of diagram (2.7) and diagram (1.5) that for all the following identities hold:
[TABLE]
Expression (2.10) is clearly equivalent to , since is an automorphism. Now since is symplectic–toric, by the proof of the Atiyah–Guillemin–Sternberg convexity theorem we know that each fiber of the momentum map consists of a single connected orbit which together with the last equality implies that . Since is the union of the orbit images , we immediately obtain that , which concludes the proof. ∎
It is possible to explicitly describe the momentum image , and for this purpose we recall the notion of –length: if , we say that a segment line joining to in has -length if there exists a matrix such that ( is not defined in general, only for segments of rational slope). The Euclidean length of a segment line agrees with its -length if and only if the segment is parallel to one of the coordinate axes in .
In their article [16], Karshon and Tolman made the following two definitions. Let be a connected symplectic -dimensional manifold with momentum map for an action of an -torus on , and let be an open convex subset which contains the image of under the momentum map . The quadruple is a proper Hamiltonian - manifold if the momentum map is proper as a map to .
The proper Hamiltonian -manifold is said to be centered about a point if is contained in the momentum map image of every component of , for each . Here
[TABLE]
where denotes the action of on . The following lemma is Proposition 2.8 in [16].
Lemma 2.2** (Karshon–Tolman, [16]).**
Let the quadruple be a proper Hamiltonian -dimensional -manifold. Suppose that is centered about and that the preimage consists of a single fixed point . Then is equivariantly symplectomorphic to
[TABLE]
where are the weights of the isotropy representation of on .
We use Lemma 2.2 in order to prove the following lemma.
Lemma 2.3**.**
The momentum image equals the subset of given by the convex hull of and , where . Furthermore, the infimum of the -lengths of the edges of meeting at is greater than or equal to , if and only if for all there exists an embedding which is -equivariant and symplectic, satisfying .
Proof.
The first observation is that equals the convex hull in of [math] and . Secondly, since is onto, it follows from diagram (2.7) that
[TABLE]
Since is an automorphism, is an automorphism of the corresponding dual spaces and therefore there exists a permutation such that . Then the linearity of implies that equals the the convex hull in of the points and , , which proves the first claim.
Suppose that the infimum of the -lengths of the edges meeting at is greater than or equal to . Let be the convex hull of and , with , and let be the convex hull of , with . Notice that , is open in , and let be the open half–space of , whose closure’s boundary is the hyperplane of that contains , and such that .
Let and let be the symplectic form obtained by restricting to . The set is open in because it is the preimage of the open set under the momentum map . By the proof of Atiyah–Guillemin–Sternberg convexity theorem, cf. [1], [8], is a connected manifold. Since is compact, the momentum map is a proper map and therefore its restriction is a proper map, which means that is proper, since . Therefore is a connected symplectic manifold with momentum map , and the quadruple is a proper Hamiltonian -space.
On the other hand, notice that the quadruple is centered about the point , and , so we can apply Lemma 2.2, and conclude that is equivariantly symplectomorphic to the submanifold given by
[TABLE]
Hence there exists an equivariant symplectomorphism , and by letting be the standard inclusion, if , the map , where is the inclusion map, is an equivariant symplectic embedding for all with . The converse follows from the first statement of the lemma. ∎
Note that only depends on the fixed point and the radius (which was fixed a priori) and not on . In Figure 3 several momentum ball images are drawn using Lemma 2.3. Note that the shaded triangle on the right picture is not a Delzant polytope since it fails to be smooth at . Delzant polytopes are simple, edge–rational and smooth polytopes, cf. Figure 2 (see [10] or [6] for a definition of these notions).
Step 2: A deformation retraction on .
In this step we use Alexander’s trick to construct a deformation retraction from the space of equivariant symplectomorphisms of the -dimensional ball in onto a disjoint union of copies of . The continuity of this deformation is standard and may be found in [13].
Lemma 2.4**.**
The space of equivariant symplectomorphisms of the -dimen-sional ball in , with respect to the standard symplectic form and the canonical action of by rotations, deformation retracts onto its subspace of linear, equivariant and symplectic rotations given by matrices in .
Proof.
We define the transformation from into , by the formula , where is the composite map
[TABLE]
The map in expression (2.11) denotes the linear contraction of factor on , ; and when , is defined to be the tangent mapping of the map , evaluated at . (This expression for is known as Alexander’s trick.) It is easy to check that is continuous and that the evaluation map given by is smooth. Since is the identity on linear maps, we conclude that it is a deformation retraction, not only a homotopy, onto the space of ball rotations by matrices with (the symmetric group) and .
We have left to check that is well defined, i.e. that . Indeed, the equivariance of the mapping follows directly from formula (2.11); explicitely we have that if is equivariant with respect to , then for all . By differentiating formula (2.11) we obtain that
[TABLE]
and since is a linear isomorphism, the mapping is a diffeomorphism. Furthermore, since the mapping is symplectic, it follows from expression (2.12) that for all we have that , for every pair of vectors , and hence is a symplectic mapping. Therefore is a diffeomorphism, which is equivariant and symplectic, or equivalently . We have been assuming that , but if , it is trivial that . ∎
Corollary 2.5**.**
The space of equivariant symplectomorphisms of the -dim-ensional ball in , with respect to the standard symplectic form and the canonical action of by rotations, is homotopically equivalent to a disjoint union of copies of .
Proof.
Apply Lemma 2.4 and observe that the space of ball rotations by matrices with and is homotopically equivalent to a disjoint union of copies of . ∎
We conclude the proof with Step 3, in which Lemma 2.1, Lemma 2.3 and Lemma 2.4 are combined in order to prove Theorem 1.2. The proof of Proposition 1.4 will follow from the proof of Theorem 1.2, since the function will be explicitly computed.
Step 3: Lifting the deformation to and conclusion.
In this final step we show that is homotopically equivalent to a disjoint union of copies of .
Lemma 2.6**.**
Suppose that the infimum of the -lengths of the edges of meeting at is strictly greater than . Then there exists an equivariant and symplectic embedding with such that if is the identification map on which takes values on and is given by formula , where , the space is homotopically equivalent to the space .
Proof.
The first observation is that by Lemma 2.3 there exists a -equivariant and symplectic embedding from into with . In order to construct homotopy equivalences between and , we define to be the identification map on which takes values in and is given by formula for every . Now we claim that the map from to , given by the commutative diagram (2.17) below, is a well–defined and continuous homotopy satisfying , while is preserved at time , i.e. we have that . The diagram is the following:
[TABLE]
The mapping is well defined by Lemma 2.1. Note that is continuous, since the identifications and are obviously continuous and we showed in Lemma 2.4 that is continuous. We can therefore conclude, from the previous considerations and the fact that that is a deformation retraction in the -Whitney topology, that induces homotopy equivalences and between and , with homotopic to and . ∎
In order to conclude the proof of Theorem 1.2 we simply make the following observations:
- •
First, the space described in it is precisely the disjoint union of the , being a vertex of , because is to be mapped to a fixed point of .
- •
The number of -fixed points, which is the same as the number of vertices of , is precisely . This follows from the analysis of the momentum map as in Atiyah–Delzant–Guillemin–Sternberg theory (see for example [10], [11]).
- •
If we denote by the number of copies of onto which the space considered in Theorem 1.2 retracts (see formula (1.6)), is obtained by multiplying the number of fixed points that admit such an embedding (see Lemma 2.3) by the number of copies of onto which (for the particular point) retracts; this latter number is (see Corollary 2.5), i.e. as many copies of as possible ways that the canonical basis vectors may be mapped onto the basis of weights (for the particular point). Also, the former number is by Lemma 2.3 controlled by the Boolean variable defined in Proposition 1.4. Therefore is given by , as we wanted to show.
- •
It is obviously true that if is equivariantly symplectomorphic to , then , so the integer is a symplectic–toric invariant.
As a final remark we observe that the invariant function associated to the Delzant manifold always reaches its minimum and maximum values on an interval of strictly positive length.
Lemma 2.7**.**
There exist numbers such that if , then the space of equivariant symplectic embeddings from into is homotopically equivalent to a disjoint union of copies of , and if , then it is empty.
Proof.
It follows easily from Lemma 2.3, Corollary 2.5 and the previous observations. ∎
This concludes the proof of Theorem 1.2 (and hence by construction the proof of Proposition 1.4).
3 Remarks on the partially equivariant case of Theorem 1.2
In this section we initiate a discussion on the topology of the space of partially equivariant symplectic embeddings and sketch some suggestions to answer a question in this direction.
First the notion of -equivariance () in Section 1 has a natural extension: we say that an embedding from the -ball into the -dimensional Delzant manifold is -equivariant with respect to a monomorphism , , if the following diagram commutes:
[TABLE]
For example, is the set of such that for all , and the rest of terminology is also analogous. This definition extends naturally to the case when , in which the embeddings considered are purely symplectic, as well as to the case when , in which the embeddings are fully equivariant, case which we treated previously in the paper. Unless otherwise specified we do not consider these two cases in the discussion that follows. The question we would like to address is the following:
**Question 3.1 ** Let be such that any connected component of admits a Darboux–Weinstein neighborhood of radius , and by this we mean a neighborhood that is equivariantly symplectomorphic to a bundle over with fiber the standard ball of radius . Is the space of -equivariant symplectic embeddings from into homotopically equivalent to the space of purely symplectic embeddings from into up to reparametrization groups (as explained below)?
To analyze Question 3 first define to be the embedded -ball in , i.e. the set of points in so that . The preimage under the momentum map of the -face corresponding to is the fixed point locus . Now consider any symplectic embedding . We want to find a canonical way to extend to an equivariant symplectic embedding up to homotopy.
Here is an attempt to construct : near the image of , we can apply the equivariant version of the Darboux–Weinstein’s theorem in order to find a neighborhood of in which is symplectomorphic to , with the action of given by the standard action on , and the symplectic form coinciding with the product symplectic form. Note that the symplectic normal bundle to is trivial over because is contractible, so a neighborhood of looks like with a product symplectic form, and the action of on it is conjugate to the standard one. Using this identification is described as a product, and we can define . This expression for is clearly symplectic and equivariant with respect to -actions on the last coordinates but is not canonical because the local symplectomorphism given by Darboux–Weinstein’s theorem is not unique. We cannot expect it to always be the same independently of , because it is not true that globally the normal bundle to is symplectically trivial, it only becomes true over a neighborhood of . So this construction depends on choices of parameters.
Calling CAN the space of canonical embeddings , where is a symplectic embedding, observe that CAN is naturally identified with the space of purely symplectic embeddings from the standard into , up to homotopy. The question then becomes whether any -equivariant symplectic embedding may be deformed through a continuous family of equivariant symplectic embeddings to an embedding in CAN.
Equivalently, we ask the question: is the natural map between the space of partially equivariant embeddings from into and the space of symplectic embeddings from into the fixed point set (given by the restriction to the fixed ball ) a fibration? Note that the construction of would give a section of this fibration.
Conjecture 3.1**.**
Question 3.1 has an affirmative answer.
**Example 3.2 ** If with a product symplectic form and product -action (this space has been carefully studied by Lalonde–Pinsonnault [14] and Anjos [2] among other authors), the fixed point locus of the second factor is , where are the fixed points of the action of on . Now, given a symplectic embedding of the ball into , it is easy to build an -equivariant embedding of into canonically by , where is taken to be a coordinate centered at the fixed point . In this case the normal bundle to the fixed point component is globally trivial.
The combination of purely symplectic results of Biran, Lalonde–Pinsonnault and others and an affirmative answer to Question 3.1 would give insight into the partially equivariant case in higher dimensions; for example McDuff showed that if is a symplectic -manifold with non-simple Seiberg–Witten type, then the space of symplectic embeddings from into is path connected (which extends results of Biran). This is a consequence of the non–trivial result: any two cohomologous and deformation equivalent symplectic forms on are isotopic (proved in [17]). Examples are known in dimensions 6 and above of cohomologous symplectic forms that are deformation equivalent but not isotopic, so these techniques do not help to understand the topology of the space of symplectic embeddings from into . A positive answer to Question 3 would give the first non–trivial result in dimension .
Another way of trying to generalize Theorem 1.2 is to consider embeddings equivariant with respect to a complexity one action, that is, an action of on . This is a hopeful approach since a complete classification of complexity one actions has been recently achieved by Karshon and Tolman [15].
Acknowledgments
The author is grateful to D. Auroux and V. Guillemin for discussions, and for hosting him at the M.I.T. regularly during the Fall and Spring semesters of 2003 and 2004. He thanks D. Auroux, J.J. Duistermaat, Y. Karshon and M. Pinsonnault for making comments on a preliminary version of this paper. Finally, the author is grateful to an anonymous referee for helpful suggestions that have shortened the proof in Section 2, as well as for his/her interesting comments on Section 3.
The reference list from the paper itself. Each links out to its DOI / PubMed record.
- 1[1] M. Atiyah, Convexity and commuting Hamiltonians. Bull. London Math. Soc. , 1 (1982) 1–15.
- 2[2] S. Anjos, Homotopy type of symplectomorphism groups of S 2 × S 2 superscript 𝑆 2 superscript 𝑆 2 S^{2}\times S^{2} . Geom. Topol. 6 (2002) 195–218.
- 3[3] P. Biran, Connectedness of spaces of symplectic embeddings, Int. Math. Res. Lett. , 10 (1996) 487–491.
- 4[4] P. Biran, From symplectic packing to algebraic geometry and back, Proc. 3rd Europ. Congr. of Math. , Barcelona 2 , Prog. Math., Birkhauser (2001) 507–524.
- 5[5] P. Biran, Geometry of symplectic intersections, Proc. ICM Beijing III (2004) 1-3.
- 6[6] A. Cannas da Silva, Lectures in symplectic geometry , Springer-Verlag, Berlin (2000).
- 7[7] T. Delzant, Periodic Hamiltonians and convex images of the momentum mapping, Bull. Soc. Math. France , 116 (1988) 315–339.
- 8[8] V. Guillemin and S. Sternberg, Convexity properties of the momentum mapping, Invent. Math. , 67 (1982) 491–513.