The Colin de Verdi\`ere number and graphs of polytopes
Ivan Izmestiev

TL;DR
This paper extends Lovász's construction linking the Colin de Verdière number to convex polytopes, showing that the number is at least the dimension for graphs of convex polytopes, using volume Hessians and Minkowski inequalities.
Contribution
It generalizes Lovász's 3D polytope construction to higher dimensions by relating the Colin de Verdière number to the volume Hessian of polar duals.
Findings
The Colin de Verdière number is at least the polytope dimension.
The construction uses the Hessian of the volume of the polar dual.
The signature of the Hessian is determined by Minkowski inequalities.
Abstract
The Colin de Verdi\`ere number of a graph is the maximum corank of a Colin de Verdi\`ere matrix for (that is, of a Schr\"odinger operator on with a single negative eigenvalue). In 2001, Lov\'asz gave a construction that associated to every convex 3-polytope a Colin de Verdi\`ere matrix of corank 3 for its 1-skeleton. We generalize the Lov\'asz construction to higher dimensions by interpreting it as minus the Hessian matrix of the volume of the polar dual. As a corollary, if is the 1-skeleton of a convex -polytope. Determination of the signature of the Hessian of the volume is based on the second Minkowski inequality for mixed volumes and on Bol's condition for equality.
Click any figure to enlarge with its caption.
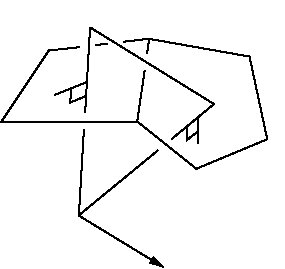 Figure 1
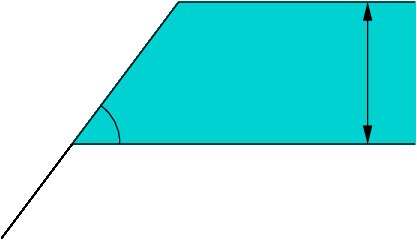 Figure 2
Peer Reviews
No public reviews on file for this paper yet. If you reviewed it on a platform where reviews are public (OpenReview, ICLR, NeurIPS, ICML), you can paste yours below so the community can read it here.
Videos
No videos yet. Explain this paper in a talk, walkthrough, or lecture? Add one.
Taxonomy
TopicsGraph theory and applications · Advanced Combinatorial Mathematics · Point processes and geometric inequalities
The Colin de Verdière number
and graphs of polytopes
Ivan Izmestiev
Institut für Mathematik
Technische Universität Berlin
Str. des 17. Juni 136
10623 Berlin, Germany
[email protected] Research for this article was supported by the DFG Research Unit 565 “Polyhedral Surfaces”.
(July 25, 2008)
Abstract
The Colin de Verdière number of a graph is the maximum corank of a Colin de Verdière matrix for (that is, of a Schrödinger operator on with a single negative eigenvalue). In 2001, Lovász gave a construction that associated to every convex 3-polytope a Colin de Verdière matrix of corank 3 for its 1-skeleton.
We generalize the Lovász construction to higher dimensions by interpreting it as minus the Hessian matrix of the volume of the polar dual. As a corollary, if is the 1-skeleton of a convex -polytope.
Determination of the signature of the Hessian of the volume is based on the second Minkowski inequality for mixed volumes and on Bol’s condition for equality.
1 Introduction
1.1 The Colin de Verdière number
At the end of 80’s, Yves Colin de Verdière introduced a graph parameter based on spectral properties of certain matrices associated with the graph .
Definition 1.1
Let be a graph with vertices. A Colin de Verdière matrix for is a symmetric matrix with the following properties.
- (M1)
* is a Schrödinger operator on , that is*
[TABLE] 2. (M2)
* has exactly one negative eigenvalue, and this eigenvalue is simple.* 3. (M3)
If is a symmetric matrix such that and whenever or is an edge of , then .
The set of all Colin de Verdière matrices for graph is denoted by . The Colin de Verdière number is defined as the maximum corank of matrices from :
[TABLE]
A Colin de Verdière matrix of maximum corank is called optimal.
Basically, the Colin de Verdière number is the maximum multiplicity of the second least eigenvalue of a discrete Schrödinger operator satisfying a certain stability assumption (M3). By replacing with , we can make the second eigenvalue zero (M2), so that multiplicity becomes corank. Definition 1.1 was motivated by the study of Schrödinger and Laplace operators associated with degenerating families of Riemannian metrics on surfaces.
The parameter turned out to be interesting on its own. In particular, it posesses the minor monotonicity property: if a graph is a minor of , then . By the Robertson-Seymour theorem this implies that graphs with can be characterized by a finite set of forbidden minors. For up to four such characterizations are known and allow nice topological reformulations: e. g. iff is planar (that is doesn’t have or as minors), and iff is linklessly embeddable in (that is doesn’t have any graph of the Petersen family as a minor). An overview of results and open problems on the Colin de Verdière number can be found in [4], [14], and [5]. The book [4] deals also with other spectral invariants arising from discrete Schrödinger and Laplace operators.
1.2 Nullspace representations and Steinitz representations
Let be a Colin de Verdière matrix for graph with . Choose a basis for , fix a coordinate system in , and read off the coordinates of :
[TABLE]
The map that associates to every vertex of the vector is called a nullspace representation of the graph .
Nullspace representations were studied in [11]. In a subsequent paper [10] Lovász showed that, for a 3-connected planar , the nullspace representation with properly scaled vectors realizes as the skeleton of a convex -polytope. Lovász provided also an inverse construction that associated to every convex 3-polytope with 1-skeleton a Colin de Verdère matrix of corank . The proof that the constructed matrix had an appropriate signature was indirect, and a more geometric approach was desirable.
1.3 Hessian matrix of the volume as a Colin de Verdière matrix
In this paper we relate the Lovász construction (that of a matrix from a polytope) to the mixed volumes. Our approach allows a straightforward generalization to higher dimensions. That is, we associate to every -dimensional convex polytope with -skeleton a Colin de Verdière matrix for of corank .
As a consequence, the graph of a convex -dimensional polytope has Colin de Verdière number at least . This result is not really new, since it follows from the minor monotonicity of , from the fact that the graph of a -polytope has as a minor [8], and from .
Our result is based on the following observation. Take a convex -polytope and deform it by shifting every facet parallelly to itself. Then the Hessian matrix of the volume of , where partial derivatives are taken with respect to the distances of the shifts, has corank and exactly one positive eigenvalue. Besides, the mixed partial derivative is positive if the th and the th facets are adjacent, and vanishes otherwise. Thus the negative of the Hessian matrix satisfies conditions (M1) and (M2) from Definition 1.1. The condition (M3) follows quite easily, too.
The signature of the Hessian of the volume is encoded in the second Minkowski inequality for mixed volumes together with Bol’s characterization of the case of equality. For simple polytopes, the determination of the signature of the Hessian is an essential part in the proof of the Alexandrov-Fenchel inequality.
1.4 Plan of the paper
In Section 2.1 we recall the Lovász construction of a Colin de Verdière matrix for the skeleton of a convex 3-polytope .
After inroducing some terminology and notation in Section 2.2, we show in Section 2.3 that the Lovász matrix is minus the Hessian matrix of the volume of the polar dual polytope .
In Section 2.4, dealing with 3-polytopes, we point out an interesting identity (first found and used elsewhere [2]) between the Hessian matrix of and the Hessian matrix of another geometric quantity associated with . This gives another interpretation of the Lovász matrix and relates the equality with the infinitesimal rigidity of the polytope .
In Section 3.1 we discuss the (im)possibility of inverting the construction, that is of finding a convex polytope whose Hessian matrix of the volume equals to a given Colin de Verdière matrix.
In Section 3.2 we give an estimate of the negative eigenvalue (and thus of the spectral gap) for the Hessian matrices of the volume.
Finally, in the Appendix we derive the signature of the Hessian from the second Minkowski inequality and Bol’s condition. Although this seems to be a folklore knowledge in narrow circles, we failed to find a written account on this subject.
1.5 Acknowledgements
I am grateful to the organizers of the 2006 Oberwolfach conference “Discrete Differential Geometry”, where the idea of this paper was born. I also thank Ronald Wotzlaw for pointing me out a mistake in a preliminary version.
2 From a convex polytope to a Colin de Verdière matrix
2.1 Lovász construction
Let us recall the Lovász construction of an optimal Colin de Verdière matrix associated with a polytopal representation of a graph in .
Let be a convex polytope containing the coordinate origin in its interior. Let be the 1-skeleton of . We denote the vertices of by , and the corresponding vertices of by . Let be the polar dual of . The vertices of are denoted by , where are faces of .
For , consider the edge of and the dual edge of , see Figure 1. It is easy to show that the vector is orthogonal to both vectors and , hence parallel to their cross product . Thus we have
[TABLE]
with (we agree to choose the labeling of and so that we get the correct sign).
Further, consider the vector
[TABLE]
where the sum extends over all vertices of adjacent to . From (1) it is easy to see that . Thus there exists a real number such that
[TABLE]
Putting for distinct non-adjacent vertices and of , we complete the construction of the matrix .
Theorem 2.1** (Lovász, [10])**
The matrix is a Colin de Verdière matrix for the graph .
The equation (2) can be rewritten as
[TABLE]
Thus has corank at least 3. Since for planar graphs, is an optimal Colin de Verdière matrix for .
The proof of Theorem 2.1 goes through a deformation argument, using the fact that the space of convex -polytopes with a given graph is connected.
2.2 Polytopes with a given set of normals
Here we fix some terminology and notation needed in the subsequent sections.
All polytopes in this paper are assumed to be convex. A facet of a -dimensional polytope is a -dimensional face of it.
We will study families of polytopes with fixed facet normals. Let be vectors in such that the coordinate origin lies in the interior of their convex hull. Consider a matrix formed by row vectors :
[TABLE]
Definition 2.2
Denote by the set of all convex polytopes with the outer facet normals .
Every polytope in is the solution set of a system of linear inequalities:
[TABLE]
where . Denote by the facet of with the outer normal . We have
[TABLE]
The numbers are called the support parameters of the polytope . The map embeds into as an open convex subset. The support parameter is proportional to the signed distance from [math] to the affine hull of the facet :
[TABLE]
By we denote the volume of a -dimensional polytope. We use the subscript because both and will occur in our formulas. We omit the subscript at , when it seems reasonable to do so.
2.3 Interpreting and generalizing the Lovász construction
By definition of the polar dual, we have
[TABLE]
Thus can be viewed as an element of the set of polytopes with facet normals . In terms of Section 2.2, . Let’s vary the support parameters of and look how does this change its volume.
Lemma 2.3
Let be the matrix constructed in Section 2.1. Then we have
[TABLE]
where is as in Section 2.2.
- *Proof *. Let be the facet of with the normal . It is not hard to show that
[TABLE]
Further, for we have
[TABLE]
if faces and are adjacent; otherwise this derivative is zero. Here is the common edge of and , and is the angle between the vectors and (i. e. the outer dihedral angle at the edge ). The equations are illustrated in Figure 2 in one dimension lower and for .
Thus at we have
[TABLE]
for all .
To deal with the case , differentiate the well-known identity
[TABLE]
with respect to . This gives
[TABLE]
In view of (3) and (4), we have .
Lemma 2.3 suggests the following generalization of the Lovász construction.
Theorem 2.4
Let
[TABLE]
be a convex polytope with outer facet normals and support parameters . Let be the dual 1-skeleton of . Then the matrix defined by
[TABLE]
is a Colin de Verdiére matrix for the graph .
The corank of is equal to . In particular, for every graph that can be realized as the 1-skeleton of a -dimensional polytope.
- *Proof *. Similarly to Lemma 2.3, for adjacent facets and we have
[TABLE]
where is their common -face, and is the angle between and . For non-adjacent and this derivative is zero. Therefore matrix satisfies property (M1) from Definition 1.1.
The proof of property (M2) is the most interesting part of the theorem. The signature of the Hessian of the volume is encoded in the second Minkowski inequality for mixed volumes enhanced by Bol’s condition for equality.
Theorem A.10 in Section A states in particular that the matrix has corank . The kernel of is easy to identify: due to the equation (5) it consists of the vectors such that for some vector .
Assuming this description of , let us prove that the matrix satisfies property (M3). If , then there are vectors such that for all . Fix . Then by assumption on we have and for all . But the normal to the face and the normals to the neighboring faces span the space . Thus we have for all , which implies .
As for the last sentence of the theorem, if is the dual 1-skeleton of a convex polytope , then is the skeleton of the polar , where is any interior point of .
2.4 Case and infinitesimal rigidity of convex polytopes
In the case there is another interpretation of the matrix . As in Section 2.1, let be a convex polytope that has skeleton and contains [math] in the interior. Triangulate the faces of by diagonals and cut into pyramids with apices at [math] and triangles of the triangulation as bases. Denote by the length of the edge that joins [math] to the vertex of . Now deform the pyramids by changing the lengths and leaving the lengths of boundary edges constant. During such deformation, the dihedral angles of the pyramids change, and the total angle around the -th edge can become different from . By computing the derivatives of explicitly, we obtain ([2], Theorem 3.11)
[TABLE]
where we use the notations from Section 2.3. If we change the variables to , so that is the distance of [math] from , then the equation (7) takes a particularly nice form
[TABLE]
By (7), the matrix is obtained from the matrix by multiplying the -th row and the -th column with , for all . This implies
Corollary 2.5
The matrix is an optimal Colin de Verdière matrix for graph .
The fact that the matrix has corank 3 is equivalent to the infinitesimal rigidity of the polytope . Indeed, every infinitesimal deformation such that for all gives rise to an infinitesimal isometric deformation of . The resulting deformation is trivial iff it is produced by moving the apex [math] inside .
Another interesting fact is that the matrix is the Hessian matrix of a geometric quantity related to the polytope (deformed by varying ). Namely, put
[TABLE]
where is the “curvature” along the -th radial edge, and is the length of the edge . Then the Schläfli formula implies
[TABLE]
Hence
[TABLE]
and both matrices are equal to the negative of the Lovász matrix , up to scaling the rows and columns by .
3 Concluding remarks
3.1 What fails in the inverse construction
Let be a Colin de Verdère matrix for the graph . Is there a convex polytope such that arises from as a result of the construction described in Section 2.3? Of course, in general the answer is no, because must be the dual skeleton of , and must have dimension . In particular, all vertices of must have degrees at least . But, due to the minor monotonicity of , there exist trivalent graphs with arbitrarily large.
Nevertheless, it is worth looking at what fails when we try to reconstruct the polytope from matrix .
Let be a basis of . Let be the -th row in the matrix . Then we have
[TABLE]
for all . Therefore, the vectors are good candidates for the outer normals to the faces of the polytope . At this point we can already fail, if the following assumptions aren’t fulfilled:
for all , and for all ; 2. 2.
for every , the projections of on for satisfy the previous assumption and span .
We proceed assuming that these conditions hold. Codimension faces of must be in 1-to-1 correspondence with the edges of , and their volumes are determined by the matrix :
[TABLE]
where is the angle between and .
Lemma 3.1
For every , there exists a convex -dimensional polytope with outer facet normals and facet volumes , .
- *Proof *. By projecting the equation (8) on , we obtain
[TABLE]
Due to , it follows that
[TABLE]
By Minkowski’s theorem [13, Section 7.1], this implies the existence of a polytope as stated in the lemma.
The polytopes in Lemma 3.1 should become facets of the polytope . But here is the second point where the reconstruction can fail: the -th facet of might be different from the -th facet of ; the only thing we know is .
In the case , however, this suffices: are convex polygons and fit together along their edges to form a polytope . Conditions 1. and 2. above hold if we assume that is a -connected planar graph [11]. Thus for -connected planar graphs every Colin de Verdière matrix corresponds to a polytope. This is one of the results of [10].
The following example shows that even for highly connected graphs the number can be bigger than the maximum dimension of a polytope with 1-skeleton .
- **Example ** Let be the multipartite graph on vertices (the graph of an -dimensional cross-polytope). By [9], for . For the graph can also be represented as the skeleton of a -dimensional convex polytope: for this is the octahedron, for the join of two convex quadrilaterals in general position in . For , however, there is no -dimensional convex polytope with skeleton . Indeed, by studying the Gale diagram [16, Lecture 6] of a -polytope with vertices, one can show that the complement to the graph of such polytope cannot have more than edges.
Note that the equation (9) is reminiscent of the definition of a -weight in [12].
3.2 Negative eigenvalue
Theorem 3.2
Let be the negative eigenvalue of the matrix (6). Then the following inequality holds:
[TABLE]
The equality takes place iff
[TABLE]
for all and some constant .
- *Proof *. By induction on , it is easy to show that the function is a degree homogeneous polynomial in as long as the combinatorics of does not change. For different combinatorics, the polynomials have different coefficients. However, since is twice differentiable, we can apply Euler’s homogeneous function theorem twice at the point , independently on how generic the combinatorics of is. This yields
[TABLE]
Since , the inequality follows.
Since is the unique negative eigenvalue of , the inequality turns into equality iff for some . We have
[TABLE]
Thus is equivalent to , and the theorem is proved.
The number is called the spectral gap. In our case by definition. Thus Theorem 3.2 provides an estimate on the spectral gap of the matrix .
Usually, one seeks to make the spectral gap as large as possible, but in order this to make sense for Colin de Verdère matices, one has to choose a matrix norm, [4, Chapter 5.7]. The norm of the matrix (6) is a function of its coefficients, which have a geometric meaning. Thus, as soon as the choice of a matrix norm is made, one can try to solve the problem of the spectral gap by geometric means (at least for 3-connected planar graphs, for which every optimal Colin de Verdière matrix can be realized through a polytope).
Appendix A The second Minkowski inequality for mixed volumes and the signature of the matrix
The goal of this appendix is to prove Theorem A.10 that describes the signature of the matrix (6). The theorem is derived from the second Minkowski inequality for mixed volumes and Bol’s condition for equality.
The relation between the theory of mixed volumes and infinitesimal rigidity (as we know, the rank of matrix (6) accounts for the infinitesimal rigidity of the dual polytope, see Section 2.4) was noticed long ago [1, 15]. In the decades thereafter this phenomenon seemed to be forgotten. Quite recently, Carl Lee and Paul Filliman [7] discovered it again.
A.1 The second Minkowski inequality and Bol’s condition
Definition A.1
Let be convex bodies. A mixed volume of and is a coefficient in the expansion
[TABLE]
with , where for denotes the Minkowski sum. In particular,
[TABLE]
In a similar way one defines the mixed volume of more than two convex bodies. It turns out that the mixed volume is polylinear with respect to the Minkowski addition and multiplication with positive scalars. A proof that the expansion (10) takes place and more information on mixed volumes can be found in [6, 13].
Theorem A.2
Let be convex bodies. Then the following holds:
(The second Minkowski inequality)
[TABLE] 2. 2.
(Bol’s condition) Assume that . Then equality holds in (11) if and only if either or is homothetic to a -tangential body of .
For a proof see [13, Theorem 6.2.1, Theorem 6.6.18]. Bol’s condition was conjectured by Minkowski but proved only decades later by Bol, [3].
Definition A.3
If are -dimensional convex polytopes, then is called a -tangential body of iff has a non-empty intersection with every face of of dimension at least .
A.2 Mixed volumes as derivatives of the volume
By substituting in (10) and , we obtain
[TABLE]
for all , which can be seen as the Taylor expansion of . We will look at it in the case when and are polytopes with the same sets of facet normals.
The space of all polytopes with outer facet normals is defined in Section 2.2. We want to study the partial derivatives of the volume of with respect to the support parameters . For brevity, let’s use the notation
[TABLE]
Similarly, the mixed volume of polytopes from will be written as a function of the support parameters:
[TABLE]
Now we would like to compute with the help of (12). This is not as straightforward as it seems, because the support parameters behave not quite linearly under the Minkowski addition. We have for . Also we have , but the equality doesn’t always hold. To describe the cases in which we do have the equality, we need a new definition.
Definition A.4
The normal cone of the face of a polytope is the set of vectors such that
[TABLE]
The normal fan is the decomposition of into the normal cones of the faces of . If the normal fan subdivides the normal fan , then we write .
Note that the normal fan of a polytope has the rays as 1-dimensional cones. The higher-dimensional cones of the normal fan determine the combinatorics of . Therefore polytopes with equal normal fans are sometimes called strongly isomorphic.
We denote the normal fans of the polytopes from by . The following lemma is classical.
Lemma A.5
If , then .
Now we are ready to prove
Lemma A.6
Let be such that . Then
[TABLE]
where denotes the directional derivative along .
[TABLE]
which implies the lemma.
Remark. For polytopes with the same normal fan (“strongly isomorphic polytopes”), there is the following description of mixed volumes. Denote
[TABLE]
By induction on , it is easy to show that there exists a homogeneous polynomial of degree in variables such that
[TABLE]
for all . If we use the same symbol to denote the associated symmetric polylinear form, then we have
[TABLE]
for all .
A.3 From the second Minkowski inequality to the signature of the Hessian of the volume
By geometric arguments similar to those in the proof of Lemma 2.3, the function is twice continuously differentiable on . Therefore the following definition makes sense.
Definition A.7
Let . Define a symmetric bilinear form on by
[TABLE]
Let be such that . By combining Euler’s homogeneous function theorem and Lemma A.6, we obtain
[TABLE]
Lemma A.8
Let be a -dimensional vector subspace such that . Then the restriction of the form to has signature or .
- *Proof *. Let be such that . The second Minkowski inequality (11) applied to and can be rewritten as
[TABLE]
Since, moreover, , it follows that the restriction of to has signature or .
It remains to show that every -subspace can be represented as with . This is true since is an interior point of the set . (When we perturb , we can create new faces, but cannot destroy old ones.)
Lemma A.9
The form has corank .
- *Proof *. Let us exhibit a -dimensional subspace of . Associate with every point a vector with coordinates
[TABLE]
The polytope is the translate of by . Therefore the directional derivative vanishes for all , which implies for all . Thus we have
[TABLE]
for all .
Let . We need to show that for some . Denote the span of and by . Then, by Lemma A.8, the restriction has signature and hence
[TABLE]
Choose such that , and and are linearly independent. Then the degeneracy of means that we have an equality in (13) and thus also in the Minkowski inequality for and . By Bol’s condition, see Theorem A.2, this happens if and only if the polytope is homothetic to a -tangential body of the polytope . By studying Definition A.3, we see that in it is equivalent to being homothetic to . If is homothetic to , then for some , thus . Since , it follows that
[TABLE]
By comparing this to (14), we conclude that for some . Thus the kernel of is confined to the vectors of the form .
Theorem A.10
The form has corank and exactly one positive eigenvalue, which is simple.
- *Proof *. The corank of is computed in Lemma A.9.
The form has at least one positive eigenvector since . Assume that it has more than one. Then there exists a -subspace of on which is positively definite. The subgroup of that preserves acts transitively on the cone of positive directions. Thus there is a positive -subspace that passes through . This contradicts Lemma A.8. Theorem is proved.
The reference list from the paper itself. Each links out to its DOI / PubMed record.
- 1[1] W. Blaschke. Ein Beweis für die Unverbiegbarkeit geschlossener konvexer Flächen. Gött. Nachr. , pages 607–610, 1912.
- 2[2] A. Bobenko and I. Izmestiev. Alexandrov’s theorem, weighted Delaunay triangulations, and mixed volumes. Ann. Inst. Fourier (Grenoble) , 58(2):447–505, 2008.
- 3[3] G. Bol. Beweis einer Vermutung von H. Minkowski. Abh. Math. Sem. Hansischen Univ. , 15:37–56, 1943.
- 4[4] Y. Colin de Verdière. Spectres de graphes , volume 4 of Cours Spécialisés . Société Mathématique de France, Paris, 1998.
- 5[5] Y. Colin de Verdière. Sur le spectre des opérateurs de type Schrödinger sur les graphes. In Graphes , pages 25–52. Ed. Éc. Polytech., Palaiseau, 2004.
- 6[6] G. Ewald. Combinatorial convexity and algebraic geometry , volume 168 of Graduate Texts in Mathematics . Springer-Verlag, New York, 1996.
- 7[7] P. Filliman. Rigidity and the Alexandrov-Fenchel inequality. Monatsh. Math. , 113(1):1–22, 1992.
- 8[8] B. Grünbaum. Convex polytopes , volume 221 of Graduate Texts in Mathematics . Springer-Verlag, New York, second edition, 2003. Prepared and with a preface by Volker Kaibel, Victor Klee and Günter M. Ziegler.